
Section 3.8 Linear Systems in Higher Dimensions

Suppose that we have two masses on a table, \(m_1\) and \(m_2\text{,}\) connected by three springs with the outside springs connected to two walls (Figure 3.8.1), and the masses are free to move horizontally. We will assume that the springs are uniform and all have the same spring constant \(k\text{.}\) The horizontal displacements of the springs are denoted by \(x_1(t)\) and \(x_2(t)\) for the masses \(m_1\) and \(m_2\text{,}\) respectively. Assuming that there is no damping, the only forces acting on mass \(m_1\) at time \(t\) are those of left and middle springs. The force from the left spring will be \(-kx_1\) while the force from middle spring will be \(k(x_2 - x_1)\text{.}\) By Newton’s Second Law of motion, we have
\begin{equation*} m_1 x_1'' = -kx_1 + k(x_2 - x_1). \end{equation*}
Similarly, the only forces acting on the second mass, \(m_2\text{,}\) will come from middle and right springs. Again using Newton’s Second Law,
\begin{equation*} m_2 x_2'' = -k(x_2 - x_1) - kx_2. \end{equation*}
Diagram Exploration Keyboard Controls
Key Action
Enter, A Activate keyboard driven exploration
B Activate menu driven exploration
Escape Leave exploration mode
Cursor down Explore next lower level
Cursor up Explore next upper level
Cursor right Explore next element on level
Cursor left Explore previous element on level
X Toggle expert mode
W Extra details if available
Space Repeat speech
M Activate step magnification
Comma Activate direct magnification
N Deactivate magnification
Z Toggle subtitles
C Cycle contrast settings
T Monochrome colours
L Toggle language (if available)
K Kill current sound
Y Stop sound output
O Start and stop sonification
P Repeat sonification output
Figure 3.8.1. A double spring-mass system
We now have a system of two second-order linear equations
\begin{align*} m_1 x_1'' & = -2kx_1 + kx_2\\ m_2 x_2'' & = kx_1 - 2kx_2. \end{align*}
If we define \(x_3\) and \(x_4\) by \(x_3 = x_1'\) and \(x_4 = x_2'\text{,}\) we now have first-order linear system of four equations,
\begin{align*} x_1' & = x_3\\ x_2' & = x_4\\ x_3' & = -2 \frac{k}{m_1} x_1 + \frac{k}{m_1} x_2\\ x_4' & = \frac{k}{m_2} x_1 - 2\frac{k}{m_2} x_2 \end{align*}
We can represent this system in the matrix form \({\mathbf x}' = A {\mathbf x}\text{,}\) where
\begin{equation*} A = \begin{pmatrix} 0 & 0 & 1 & 0 \\ 0 & 0 & 0 & 1 \\ -2k/m_1 & k/m_1 & 0 & 0 \\ k / m_2 & - 2k/m_2 & 0 & 0 \end{pmatrix}. \end{equation*}
We will learn how to analyze and solve such systems in the next two sections.

Subsection 3.8.1 Higher-Order Linear Systems

We can write the system
\begin{align*} x_1' & = a_{11} x_1 + \cdots a_{1n} x_n\\ x_2' & = a_{21} x_1 + \cdots a_{2n} x_n\\ & \vdots\\ x_n' & = a_{n1} x_1 + \cdots a_{nn} x_n \end{align*}
in matrix form \({\mathbf x}' = A {\mathbf x}\text{,}\) where
\begin{equation*} A = \begin{pmatrix} a_{11} & a_{12} & \cdots & a_{1n} \\ a_{21} & a_{22} & \cdots & a_{2n} \\ \vdots & \vdots & \ddots & \vdots \\ a_{n1} & a_{n2} & \cdots & a_{nn} \end{pmatrix} \qquad\text{and}\qquad {\mathbf x} = \begin{pmatrix} x_1 \\ x_2 \\ \vdots \\ x_n \end{pmatrix}. \end{equation*}
The strategy for finding solutions to the system \({\mathbf x}' = A {\mathbf x}\) is the same as for systems of two equations. If \(\lambda\) is an eigenvalue of \(A\) with eigenvector \({\mathbf v}\text{,}\)
\begin{equation*} {\mathbf x}(t) = e^{\lambda t} {\mathbf v} \end{equation*}
is a solution for our system. Indeed,
\begin{equation*} {\mathbf x}'(t) = \lambda e^{\lambda t} {\mathbf v} = e^{\lambda t} (\lambda {\mathbf v}) = e^{\lambda t} A {\mathbf v} = A(e^{\lambda t} {\mathbf v}) = A {\mathbf x}(t). \end{equation*}

Example 3.8.2.

The system
\begin{align*} x' & = -5x - 8y - 2z\\ y' & = 5x + 12y + 4z\\ z' & = -11x - 19y - 5z \end{align*}
can be rewritten as
\begin{equation*} {\mathbf x}' = \begin{pmatrix} x' \\ y' \\ z' \end{pmatrix} = \begin{pmatrix} -5 & -8 & -2 \\ 5 & 12 & 4 \\ -11 & -19 & -5 \end{pmatrix} \begin{pmatrix} x \\ y \\ z \end{pmatrix} = A {\mathbf x}. \end{equation*}
We can compute the eigenvalues of \(A\) by finding the roots of its characteristic polynomial
\begin{equation*} \det( A - \lambda I) = -\lambda^3 - 2\lambda^2 - \lambda + 2 = (\lambda - 1)(\lambda + 1)(\lambda - 2). \end{equation*}
Thus, the eigenvalues of \(A\) are \(\lambda = 2\text{,}\) \(\lambda = 1\text{,}\) and \(\lambda = -1\text{.}\) To find an eigenvector for \(\lambda = 2\text{,}\) we must find a nontrivial solution for system of equations \((A - 2I){\mathbf x} = {\mathbf 0}\text{,}\)
\begin{align*} -7x - 8y - 2z \amp = 0\\ -5x + 10y + 4z \amp = 0\\ -11x - 19y - 7z \amp = 0. \end{align*}
It is easy to check that \((2, -3, 5)\) is a solution. Similarly, we can determine that \((5, -7, 13)\) is an eigenvector for \(\lambda = 1\) and \((1, -1, 2)\) is an eigenvector for \(\lambda = -1\text{.}\) Thus, we have found three solutions for the system \({\mathbf x}' = A {\mathbf x}\text{,}\)
\begin{equation*} \mathbf x_1(t) = e^{2t} \begin{pmatrix} 2 \\ -3 \\ 5 \end{pmatrix}, \quad \mathbf x_2(t) = e^{t} \begin{pmatrix} 5 \\ -7 \\ 13 \end{pmatrix}, \quad \text{and} \quad \mathbf x_3(t) = e^{-t} \begin{pmatrix} 1 \\ -1 \\ 2 \end{pmatrix}. \end{equation*}
The Principle of Superposition also holds for higher-order systems. If \({\mathbf x}_1(t)\) and \({\mathbf x}_2(t)\) are solutions for \({\mathbf x}' = A {\mathbf x}\text{,}\) then
\begin{equation*} c_1 {\mathbf x}_1(t) + c_2 {\mathbf x}_2(t) \end{equation*}
is a solution for the system, since
\begin{align*} \frac{d}{dt}[c_1 {\mathbf x}_1(t) + c_2 {\mathbf x}_2(t)] & = c_1 \frac{d}{dt}{\mathbf x}_1(t) + c_2 \frac{d}{dt}{\mathbf x}_2(t)\\ & = c_1 A {\mathbf x}_1(t) + c_2 A {\mathbf x}_2(t)\\ & = A[c_1 {\mathbf x}_1(t) + c_2 {\mathbf x}_2(t)]. \end{align*}
Consequently,
\begin{equation*} {\mathbf x}(t) = c_1 e^{2t} \begin{pmatrix} 2 \\ -3 \\ 5 \end{pmatrix} + e^{t} \begin{pmatrix} 5 \\ -7 \\ 13 \end{pmatrix} + c_3 e^{-t} \begin{pmatrix} 1 \\ -1 \\ 2 \end{pmatrix} \end{equation*}
is a solution for our system. This is, in fact, the general solution for the system.
Although we shall not cover the notions of linear independence, canonical matrices, and change of coordinates for \({\mathbb R}^n\text{,}\) the same ideas that we used for systems of first-order linear differential equations in \({\mathbb R}^2\) carry over to \({\mathbb R}^n\text{.}\) The necessary linear algebra is covered in any good linear algebra course. Also, see Chapters 5 and 6 in [12]. In addition, finding eigenvalues for matrices greater than \(2 \times 2\text{,}\) we will need to find the roots of a characteristic polynomial of degree greater than two, which can be difficult. A good course in linear algebra will cover techniques of finding eigenvalues for larger matrices.

Example 3.8.3.

Let us see how the linear algebra works in the previous example. If we form the matrix
\begin{equation*} T = \begin{pmatrix} 2 & 5 & 1 \\ -3 & -7 & -1 \\ 5 & 13 & 2 \end{pmatrix} \end{equation*}
from the eigenvectors of \(A\text{,}\) we can convert the system \({\mathbf x}' = A {\mathbf x}\) to the system
\begin{align*} {\mathbf y}' \amp = (T^{-1} A T) {\mathbf y}\\ \amp \begin{pmatrix} 1 & -3 & -2\\ -1 & 1 & 1 \\ 4 & 1 & -1 \end{pmatrix} \begin{pmatrix} -5 & -8 & -2 \\ 5 & 12 & 4 \\ -11 & -19 & -5 \end{pmatrix} \begin{pmatrix} 2 & 5 & 1 \\ -3 & -7 & -1 \\ 5 & 13 & 2 \end{pmatrix} {\mathbf y},\\ \amp = \begin{pmatrix} 2 & 0 & 0 \\ 0 & 1 & 0 \\ 0 & 0 & -1 \end{pmatrix} {\mathbf y}, \end{align*}
which we can immediately solve:
\begin{equation*} {\mathbf y}(t) = c_1 e^{2t} \begin{pmatrix} 1 \\ 0 \\ 0 \end{pmatrix} + c_2 e^{t} \begin{pmatrix} 0 \\ 1 \\ 0 \end{pmatrix} + c_3 e^{-t} \begin{pmatrix} 0 \\ 0 \\ 1 \end{pmatrix}. \end{equation*}
Multiplying our solution by \(T\) yields the general solution
\begin{equation*} {\mathbf x}(t) = T {\mathbf y} = c_1 e^{2t} \begin{pmatrix} 2 \\ -3 \\ 5 \end{pmatrix} + e^{t} \begin{pmatrix} 5 \\ -7 \\ 13 \end{pmatrix} + c_3 e^{-t} \begin{pmatrix} 1 \\ -1 \\ 2 \end{pmatrix}, \end{equation*}
the solution to the system \(\mathbf x' A \mathbf x\text{.}\)

Subsection 3.8.2 The Geometry of Solutions

In Section 3.6, we classified all of the geometry of the solutions for planar systems using the trace-determinant plane. The geometry for linear systems in three variables is a bit more complicated. For a system
\begin{align*} x' \amp = a_1 x + a_1 y + a_3 z\\ y' \amp = b_1 x + b_2 y + b_3 z\\ z' \amp = c_1 x + c_2 y + c_3 z, \end{align*}
our solution curves live in \(\mathbb R^3\text{,}\) and there is simply a lot more room to move around in three dimensions than in two dimensions. The origin is still an equilibrium solution for a system of linear differential equations in three variables. The origin is a stable equilibrium solution if any solution \(\mathbf x(t)\) approaches \(\mathbf 0 = (0, 0, 0)\) as \(t \to \infty\text{;}\) otherwise, \(\mathbf 0\) is an unstable equilibrium solution. In the case of planar systems, an unstable solution is a nodal saddle, a nodal source, a spiral source, or a source with a single unstable line. In the case of \(\mathbb R^3\text{,}\) we could have a stable line of solutions and an unstable plane of solutions. In this case, all solutions of the system with initial condition lying on the stable line would approach the origin as \(t \to \infty\text{,}\) but all solutions with initial conditions that are a nonzero point on the unstable plane would move away from the origin.

Example 3.8.4.

In Example 3.8.2, we had solutions
\begin{equation*} \mathbf x_1(t) = e^{2t} \begin{pmatrix} 2 \\ -3 \\ 5 \end{pmatrix}, \mathbf x_2(t) = e^{t} \begin{pmatrix} 5 \\ -7 \\ 13 \end{pmatrix}, \quad \text{and} \quad \mathbf x_3(t) = e^{-t} \begin{pmatrix} 1 \\ -1 \\ 2 \end{pmatrix}. \end{equation*}
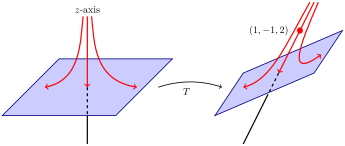
The straight line through the origin and the point \((1, -1, 2)\) is a stable line. That is, for any initial condition \({\mathbf x}(0) = (x_0, y_0, z_0)\) lying on this line, our solution will tend toward the origin as \(t \to \infty\text{.}\) On the other hand, the plane spanned by \((2, -3, 5)\) and \((5, -7, 13)\) is unstable plane. Solutions on this plane move away from the origin as \(t \to \infty\text{.}\) Of course, \((0, 0, 0)\) is an equlibrium solution for our system. We say that the origin is a saddle in this example (Figure 3.8.5).
a stable line and an unstable plane in three dimensions with a transformation to another unstable plane and stable line
Figure 3.8.5. A saddle in \({\mathbb R}^3\)

Example 3.8.6.

For the system
\begin{equation*} {\mathbf x}' = \begin{pmatrix} 0 & 1 & 0 \\ -1 & 0 & 0 \\ 0 & 0 & -1 \end{pmatrix} {\mathbf x} \end{equation*}
we have a very different type of unstable equilibrium solution. The eigenvalues of this matrix are \(\lambda = \pm i\) and \(\lambda = -1\text{.}\) Thus, a solution satisfying the initial condition \({\mathbf x}(0) = (x_0, y_0, z_0)\) is given by
\begin{equation*} {\mathbf x}(t) = x_0 \begin{pmatrix} \cos t \\ - \sin t \\ 0 \end{pmatrix} + y_0 \begin{pmatrix} \sin t \\ \cos t \\ 0 \end{pmatrix} + z_0 e^{-t} \begin{pmatrix} 0 \\ 0 \\ 1 \end{pmatrix}. \end{equation*}
If \(z_0 = 0\text{,}\) then our initial condition is in the \(xy\)-plane and all of the solutions lie on circles centered at the origin. On the other hand, if \(x_0 = 0\) and \(y_0 = 0\text{,}\) we have a stable line of solutions lying along the \(z\)-axis. In fact, each solution that does not lie on the stable line lies on a cylinder in \({\mathbb R}^3\) given by \(x^2 + y^2 = r^2\) for some constant \(r \gt 0\text{.}\) These solutions spiral towards the circular solution of radius \(r\) in the \(xy\)-plane if \(z_0 \neq 0\) (Figure 3.8.7).
Figure 3.8.7. A spiral center in \({\mathbb R}^3\)

Example 3.8.8.

For an example of a stable plane and an unstable line, let us consider the system
\begin{equation*} {\mathbf x}' = \begin{pmatrix} -1 & 1 & 0 \\ -1 & -1 & 0 \\ 0 & 0 & 1 \end{pmatrix} {\mathbf x} = A {\mathbf x}. \end{equation*}
The characteristic equation of the matrix \(A\) is
\begin{equation*} \lambda^3 + \lambda^2 - 2 = (\lambda - 1)(\lambda^2 + 2\lambda + 2) = 0. \end{equation*}
Thus, the eigenvalues of \(A\) are \(\lambda = 1\) and \(\lambda = -1 \pm i\text{.}\) Solving
\begin{equation*} [A - (-1 + i) ]{\mathbf x} = {\mathbf 0} \end{equation*}
gives us an eigenvector \((1, i, 0)\) for \(\lambda = -1 + i\text{.}\) Since
\begin{equation*} \begin{pmatrix} 1 \\ i \\ 0 \end{pmatrix} = \begin{pmatrix} 1 \\ 0 \\ 0 \end{pmatrix} + i \begin{pmatrix} 0 \\ 1 \\ 0 \end{pmatrix}, \end{equation*}
we will let \({\mathbf v}_1 = (1, 0, 0)\) and \({\mathbf v}_2 = (0, 1, 0)\text{.}\) Since \({\mathbf v}_3 = (0, 0, 1)\) is an eigenvector for \(\lambda = 1\text{,}\) our system has solution
\begin{equation*} {\mathbf x}(t) = x_0 e^{-t} \begin{pmatrix} \cos t \\ - \sin t \\ 0 \end{pmatrix} + y_0 e^{-t} \begin{pmatrix} \sin t \\ \cos t \\ 0 \end{pmatrix} + z_0 e^t \begin{pmatrix} 0 \\ 0 \\ 1 \end{pmatrix}, \end{equation*}
where \(\mathbf x(0) = (x_0, y_0, z_0)\text{.}\) If \(z_0 = 0\text{,}\) our initial condition lies in the \(xy\)-plane and solution curves spiral in towards the origin. Thus, we have a stable plane. On the other hand, if \(x_0 = 0\) and \(y_0 = 0\) but \(z_0 \neq 0\text{,}\) then our solution approaches \(\pm \infty\) as \(t \to \infty\text{.}\) In this case, the \(z\)-axis is an unstable line (Figure 3.8.9).
Figure 3.8.9. A spiral saddle in \({\mathbb R}^3\)
For an example of a stable equilibrium solution at the origin, consider the system
\begin{equation*} {\mathbf x}' = \begin{pmatrix} \lambda_1 & 0 & 0 \\ 0 & \lambda_2 & 0 \\ 0 & 0 & \lambda_3 \end{pmatrix} {\mathbf x}, \end{equation*}
where \(\lambda_3 \lt \lambda_2 \lt \lambda_1 \lt 0\text{.}\) For an initial condition \((x_0, y_0, z_0)\) with at least one coordinate nonzero, the corresponding solution tends towards the origin tangentially to the \(x\)-axis as \(t \to \infty\) (Figure 3.8.10).
Figure 3.8.10. A sink in \({\mathbb R}^3\)
Changing the system that in ExampleExample 3.8.8 to be
\begin{equation*} {\mathbf x}' = \begin{pmatrix} -1 & 1 & 0 \\ -1 & -1 & 0 \\ 0 & 0 & -1 \end{pmatrix} {\mathbf x}, \end{equation*}
we obtain the solution satisfying the initial condition \({\mathbf x}(0) = (x_0, y_0, z_0)\) to be
\begin{equation*} {\mathbf x}(t) = x_0 e^{-t} \begin{pmatrix} \cos t \\ - \sin t \\ 0 \end{pmatrix} + y_0 e^{-t} \begin{pmatrix} \sin t \\ \cos t \\ 0 \end{pmatrix} + z_0 e^{-t} \begin{pmatrix} 0 \\ 0 \\ 1 \end{pmatrix}, \end{equation*}
where \(\mathbf x(0) = (x_0, y_0, z_0)\text{.}\) In this case, all solutions will approach the origin as \(t \to \infty\text{.}\)

Activity 3.8.11 Solving Higher Order Systems.

  1. Find the eigenvalues of \(A\text{.}\) You may find Sage useful.
  2. Find the eigenvectors for each eigenvalue of \(A\text{.}\)
  3. What is the general solution of \(d\mathbf x/dt = A \mathbf x\text{?}\)
  4. Describe the nature of the nature of the solution space in \(\mathbb R^3\text{.}\) Are there stable lines or planes?

(a)

\begin{equation*} A = \begin{pmatrix} -13 & -8 & -4\\ 12 & 7 & 4\\ 24 & 16 & 7 \end{pmatrix} \end{equation*}

(b)

\begin{equation*} A = \begin{pmatrix} 2 & 1 & 1\\ 1 & 2 & 1\\ 1 & 1 & 2 \end{pmatrix} \end{equation*}

(c)

\begin{equation*} A = \begin{pmatrix} -13 & -8 & -4 \\ 12 & 7 & 4 \\ 24 & 16 & 7 \end{pmatrix} \end{equation*}

Subsection 3.8.3 The Double Spring-Mass Systems Revisited

Let us return to our spring-mass system \({\mathbf x}' = A {\mathbf x}\text{,}\) where
\begin{equation*} A = \begin{pmatrix} 0 & 0 & 1 & 0 \\ 0 & 0 & 0 & 1 \\ -2k/m_1 & k/m_1 & 0 & 0 \\ k / m_2 & - 2k/m_2 & 0 & 0 \end{pmatrix}. \end{equation*}
To keep matters simple, we will assume that \(m_1 = m_2 = k = 1\text{.}\) Thus, our matrix now becomes
\begin{equation*} A = \begin{pmatrix} 0 & 0 & 1 & 0 \\ 0 & 0 & 0 & 1 \\ -2 & 1 & 0 & 0 \\ 1 & - 2 & 0 & 0 \end{pmatrix}. \end{equation*}
The characteristic polynomial of \(A\) is
\begin{equation*} \det(A - \lambda I) = \lambda^4 + 4\lambda^2 + 3 = (\lambda^2 + 1)(\lambda^2 + 3). \end{equation*}
Thus, the eigenvalues of \(A\) are \(\lambda = \pm i\) and \(\lambda = \pm i \sqrt{3}\text{.}\) We can find eigenvectors
\begin{equation*} {\mathbf v}_1 = \begin{pmatrix} i / \sqrt{3} \\ - i / \sqrt{3} \\ -1 \\ 1 \end{pmatrix}, {\mathbf v}_2 = \begin{pmatrix} -i / \sqrt{3} \\ i / \sqrt{3} \\ -1 \\ 1 \end{pmatrix}, {\mathbf v}_3 = \begin{pmatrix} -i \\ - i \\ 1 \\ 1 \end{pmatrix}, {\mathbf v}_4 = \begin{pmatrix} i \\ i \\ 1 \\ 1 \end{pmatrix}, \end{equation*}
corresponding to the eigenvalues \(\lambda_1 = i \sqrt{3}\text{,}\) \(\lambda_2 = - i \sqrt{3}\text{,}\) \(\lambda_3 = i\text{,}\) \(\lambda_4 = - i\text{,}\) respectively. Consequently, the general solution to our system is
\begin{equation*} {\mathbf x}(t) = c_1 e^{ i \sqrt{3} t} {\mathbf v}_1 + c_1 e^{ -i \sqrt{3} t} {\mathbf v}_2 + c_1 e^{ i t} {\mathbf v}_3 + c_1 e^{ -i t} {\mathbf v}_4; \end{equation*}
however, this form of the solution is not very useful. By examining real and imaginary parts of \(e^{ i \sqrt{3} t} {\mathbf v}_1\) and \(c_1 e^{ i t} {\mathbf v}_3\text{,}\) we can rewrite the solution as
\begin{equation*} {\mathbf x}(t) = c_1 \begin{pmatrix} \cos \sqrt{3} t \\ - \cos \sqrt{3}t \\ - \sqrt{3} \sin \sqrt{3}t \\ \sqrt{3} \sin \sqrt{3}t \end{pmatrix} + c_2 \begin{pmatrix} - \sin \sqrt{3} t \\ \sin \sqrt{3}t \\ -\sqrt{3} \cos \sqrt{3} t \\ \sqrt{3} \cos \sqrt{3} t \end{pmatrix} + c_3 \begin{pmatrix} \cos t \\ \cos t \\ -\sin t \\ - \sin t \end{pmatrix} + c_4 \begin{pmatrix} \sin t \\ \sin t \\ \cos t \\ \cos t \end{pmatrix}. \end{equation*}
If we have the following initial conditions,
\begin{align*} x_1(0) & = 0\\ x_2(0) & = 0\\ x_1'(0) = x_3(0) & = 2\\ x_2'(0) = x_4(0) & = 2, \end{align*}
we can determine \(c_1 = c_2 = c_3 = 0\) and \(c_4 = 2\text{.}\) Thus, the solution to our initial value problem is
\begin{equation*} {\mathbf x}(t) = \begin{pmatrix} 2 \sin t \\ 2 \sin t \\ 2 \cos t \\ 2 \cos t \end{pmatrix}, \end{equation*}
and the two masses will oscillate with a frequency of one and an amplitude of two. We leave the details as an exercise.
Subsection 3.8.4 Important Lessons

  • \begin{align*} x_1' & = a_{11} x_1 + \cdots a_{1n} x_n\\ x_2' & = a_{21} x_1 + \cdots a_{2n} x_n\\ & \vdots\\ x_n' & = a_{n1} x_1 + \cdots a_{nn} x_n \end{align*}
    can be written in matrix form \({\mathbf x}' = A {\mathbf x}\text{,}\) where
    \begin{equation*} A = \begin{pmatrix} a_{11} & a_{12} & \cdots & a_{1n} \\ a_{21} & a_{22} & \cdots & a_{2n} \\ \vdots & \vdots & \ddots & \vdots \\ a_{n1} & a_{n2} & \cdots & a_{nn} \end{pmatrix} \qquad\text{and}\qquad {\mathbf x} = \begin{pmatrix} x_1 \\ x_2 \\ \vdots \\ x_n \end{pmatrix}. \end{equation*}
  • As in the case of \({\mathbb R}^2\text{,}\) we can solve the system \({\mathbf x}' = A {\mathbf x}\) by finding eigenvalues and eigenvectors for \(A\text{.}\)
  • The Principle of Superposition holds for higher-order systems. If \({\mathbf x}_1(t)\) and \({\mathbf x}_2(t)\) are solutions for \({\mathbf x}' = A {\mathbf x}\text{,}\) then
    \begin{equation*} c_1 {\mathbf x}_1(t) + c_2 {\mathbf x}_2(t) \end{equation*}
    is a solution for the system.
  • The geometry for a system in \({\mathbb R}^3\) is more complicated than the planar case. However, the solutions are usually characterized by stable lines or stable planes.

Reading Questions 3.8.5 Reading Questions

1.

Is it possible for a \(3 \times 3\) to have a line of stable solutions and a plane of unstable solutions? Explain.

Exercises 3.8.6 Exercises

Finding Solutions of \(3 \times 3\) Systems.

For each of the linear systems \(d\mathbf x/dt = A \mathbf x\) in Exercise Group 3.8.6.1–8
  1. Find the eigenvalues of \(A\text{.}\) You may find Sage useful.
  2. Find the eigenvectors for each eigenvalue of \(A\text{.}\)
  3. What is the general solution of \(d\mathbf x/dt = A \mathbf x\text{?}\)
  4. Describe the nature of the nature of the solution space in \(\mathbb R^3\text{.}\) Are there stable lines or planes?

1.

\begin{equation*} A = \begin{pmatrix} 4 \amp 3 \amp -1 \\ -1 \amp 0 \amp -1 \\ 1 \amp 1 \amp 2 \end{pmatrix} \end{equation*}
Solution.
Part (a): Eigenvalues. The characteristic polynomial of
\begin{equation*} A = \begin{pmatrix}4&3&-1\\-1&0&-1\\ 1&1&2\end{pmatrix} \end{equation*}
is
\begin{equation*} \det(A - \lambda I) = -(\lambda - 1)(\lambda^2 - 5\lambda + 8) = 0. \end{equation*}
The real eigenvalue is \(\lambda_1 = 1\text{,}\) and the quadratic \(\lambda^2 - 5\lambda + 8 = 0\) gives the complex conjugate pair
\begin{equation*} \lambda_{2,3} = \frac{5 \pm i\sqrt{7}}{2}. \end{equation*}
Part (b): Eigenvectors. For \(\lambda_1 = 1\text{:}\) solving \((A - I)\mathbf{v} = \mathbf{0}\text{,}\)
\begin{equation*} \begin{pmatrix}3&3&-1\\-1&-1&-1\\ 1&1&1\end{pmatrix}\mathbf{v} = \mathbf{0}. \end{equation*}
The second and third rows give \(v_1 + v_2 + v_3 = 0\text{,}\) and the first row combined with this gives \(v_1 = -v_2\text{,}\) \(v_3 = 0\text{.}\) Taking \(v_2 = 1\text{,}\)
\begin{equation*} \mathbf{v}_1 = \begin{pmatrix}-1\\1\\0\end{pmatrix}. \end{equation*}
For \(\lambda_{2,3} = \tfrac{5 \pm i\sqrt{7}}{2}\text{:}\) solving \((A - \lambda_{2}I)\mathbf{v} = \mathbf{0}\) (via Sage) gives a complex eigenvector
\begin{equation*} \mathbf{v}_2 = \mathbf{p} + i\mathbf{q} = \begin{pmatrix}3\\-1\\0\end{pmatrix} + i\begin{pmatrix}0\\\tfrac{\sqrt{7}}{2}\\ -\tfrac{\sqrt{7}}{2}\end{pmatrix}, \end{equation*}
with \(\mathbf{v}_3 = \overline{\mathbf{v}_2}\text{.}\)
Part (c): General solution. The real eigenvalue contributes the straight-line solution \(c_1 e^{t}\mathbf{v}_1\text{.}\) The complex pair \(\alpha \pm i\beta = \tfrac{5}{2} \pm i\tfrac{\sqrt{7}}{2}\) contributes two real solutions built from \(\mathbf{p}\) and \(\mathbf{q}\text{.}\) The general solution is
\begin{align*} \mathbf{x}(t) & = c_1 e^{t} \begin{pmatrix} -1\\1\\0 \end{pmatrix}\\ & + e^{5t/2}\! \left[ c_2\!\left(\mathbf{p}\cos\frac{\sqrt{7}\,t}{2} - \mathbf{q}\sin\frac{\sqrt{7}\,t}{2} \right) + c_3\!\left(\mathbf{p}\sin\frac{\sqrt{7}\,t}{2} + \mathbf{q}\cos\frac{\sqrt{7}\,t}{2}\right) \right], \end{align*}
where
\begin{equation*} \mathbf{p} = \begin{pmatrix}3\\-1\\0\end{pmatrix}, \qquad \mathbf{q} = \begin{pmatrix}0\\\tfrac{\sqrt{7}}{2}\\ -\tfrac{\sqrt{7}}{2}\end{pmatrix}. \end{equation*}
Part (d): Nature of the solution space in \(\mathbb{R}^3\text{.}\) The system has three distinct eigenvalues:
  • \(\lambda_1 = 1 \gt 0\text{:}\) the real eigenvalue gives an unstable line in the direction of \(\mathbf{v}_1 = (-1,1,0)^T\text{.}\) Solutions starting on this line move away from the origin along this direction.
  • \(\lambda_{2,3} = \tfrac{5}{2} \pm i\tfrac{\sqrt{7}}{2}\text{:}\) the complex pair has real part \(\alpha = 5/2 \gt 0\text{,}\) so these modes also grow. They contribute a two-dimensional unstable spiraling plane spanned by \(\mathbf{p}\) and \(\mathbf{q}\text{,}\) on which solutions spiral outward.
Since all eigenvalues have positive real parts, the origin is a completely unstable equilibrium: every non-trivial solution diverges to infinity. There are no stable lines or stable planes. The only invariant structures are the unstable line along \(\mathbf{v}_1\) and the unstable spiraling plane of the complex modes.

2.

\begin{equation*} A = \begin{pmatrix} -2 \amp -3 \amp 4 \\ 4 \amp 5 \amp -4 \\ 5 \amp 5 \amp -3 \end{pmatrix} \end{equation*}
Solution.
Part (a): Eigenvalues. The characteristic polynomial of
\begin{align*} A = \begin{pmatrix}-2&-3&4\\4&5&-4\\ 5&5&-3\end{pmatrix} \end{align*}
is
\begin{gather*} \det(A - \lambda I) = -\lambda^3 + 7\lambda - 6 = -(\lambda-1)(\lambda-2)(\lambda+3) = 0, \end{gather*}
giving three distinct real eigenvalues
\begin{gather*} \lambda_1 = 1, \qquad \lambda_2 = 2, \qquad \lambda_3 = -3. \end{gather*}
Part (b): Eigenvectors. For \(\lambda_1 = 1\text{:}\) solving \((A - I)\mathbf{v} = \mathbf{0}\text{,}\) the system reduces to \(v_3 = 0\) and \(v_1 = -v_2\text{,}\) giving
\begin{gather*} \mathbf{v}_1 = \begin{pmatrix}-1\\1\\0\end{pmatrix}. \end{gather*}
For \(\lambda_2 = 2\text{:}\) solving \((A - 2I)\mathbf{v} = \mathbf{0}\text{,}\) the system reduces to \(v_2 = 0\) and \(v_3 = v_1\text{,}\) giving
\begin{gather*} \mathbf{v}_2 = \begin{pmatrix}1\\0\\1\end{pmatrix}. \end{gather*}
For \(\lambda_3 = -3\text{:}\) solving \((A + 3I)\mathbf{v} = \mathbf{0}\text{,}\) the system reduces to \(v_1 = -v_2\) and \(v_3 = v_2\text{,}\) giving
\begin{gather*} \mathbf{v}_3 = \begin{pmatrix}-1\\1\\1\end{pmatrix}. \end{gather*}
Part (c): General solution. Since the three eigenvalues are distinct, the general solution is
\begin{gather*} \mathbf{x}(t) = c_1 e^{t}\begin{pmatrix}-1\\1\\0\end{pmatrix} + c_2 e^{2t}\begin{pmatrix}1\\0\\1\end{pmatrix} + c_3 e^{-3t}\begin{pmatrix}-1\\1\\1\end{pmatrix}, \end{gather*}
where \(c_1\text{,}\) \(c_2\text{,}\) and \(c_3\) are arbitrary constants.
Part (d): Nature of the solution space. The three eigenvalues and their eigenvectors determine the geometry of the solution space in \(\mathbb{R}^3\text{:}\)
  • \(\lambda_3 = -3 \lt 0\text{:}\) the eigenvector \(\mathbf{v}_3 = (-1,1,1)^T\) spans a stable line. Solutions starting on this line (i.e., with \(c_1 = c_2 = 0\)) decay to the origin exponentially as \(t \to \infty\text{.}\)
  • \(\lambda_1 = 1 \gt 0\text{:}\) the eigenvector \(\mathbf{v}_1 = (-1,1,0)^T\) spans an unstable line. Solutions on this line diverge from the origin.
  • \(\lambda_2 = 2 \gt 0\text{:}\) the eigenvector \(\mathbf{v}_2 = (1,0,1)^T\) spans a second unstable line.
  • The two unstable eigenvectors \(\mathbf{v}_1\) and \(\mathbf{v}_2\) together span an unstable plane. Solutions starting in this plane (with \(c_3 = 0\)) diverge to infinity.
  • For a generic initial condition (\(c_3 \neq 0\)), the \(e^{-3t}\) term decays while the growing terms dominate, so all solutions except those on the stable line eventually diverge. The origin is a saddle point in \(\mathbb{R}^3\text{.}\)
In summary, there is one stable line (along \(\mathbf{v}_3\)), one unstable plane (spanned by \(\mathbf{v}_1\) and \(\mathbf{v}_2\)), and no stable planes.

3.

\begin{equation*} A = \begin{pmatrix} 4 \amp 2 \amp 0 \\ 0 \amp 2 \amp 0 \\ 2 \amp 2 \amp 2 \end{pmatrix} \end{equation*}
Solution.
Part (a): Eigenvalues. Expanding the characteristic polynomial by expanding along the second row,
\begin{align*} \det(A - \lambda I) \amp = (2-\lambda)\det\begin{pmatrix}4-\lambda&0\\2&2-\lambda \end{pmatrix}\\ \amp = (2-\lambda)^2(4-\lambda) = 0, \end{align*}
giving eigenvalues
\begin{gather*} \lambda_1 = 2 \text{ (multiplicity 2)}, \qquad \lambda_2 = 4 \text{ (multiplicity 1)}. \end{gather*}
Part (b): Eigenvectors. For \(\lambda_1 = 2\text{:}\) solving \((A - 2I)\mathbf{v} = \mathbf{0}\text{,}\)
\begin{align*} \begin{pmatrix}2&2&0\\0&0&0\\ 2&2&0\end{pmatrix}\mathbf{v} = \mathbf{0}, \end{align*}
the only constraint is \(v_1 = -v_2\) with \(v_3\) free. This gives a two-dimensional eigenspace spanned by
\begin{gather*} \mathbf{v}_1 = \begin{pmatrix}-1\\1\\0\end{pmatrix}, \qquad \mathbf{v}_2 = \begin{pmatrix}0\\0\\1\end{pmatrix}. \end{gather*}
Since the geometric multiplicity equals the algebraic multiplicity, \(\lambda_1 = 2\) is semisimple (not defective).
For \(\lambda_2 = 4\text{:}\) solving \((A - 4I)\mathbf{v} = \mathbf{0}\text{,}\)
\begin{align*} \begin{pmatrix}0&2&0\\0&-2&0\\ 2&2&-2\end{pmatrix}\mathbf{v} = \mathbf{0}, \end{align*}
the constraints are \(v_2 = 0\) and \(v_1 = v_3\text{,}\) giving
\begin{gather*} \mathbf{v}_3 = \begin{pmatrix}1\\0\\1\end{pmatrix}. \end{gather*}
Part (c): General solution. Since all three eigenvalues yield independent eigenvectors, the general solution is
\begin{gather*} \mathbf{x}(t) = c_1 e^{2t}\begin{pmatrix}-1\\1\\0\end{pmatrix} + c_2 e^{2t}\begin{pmatrix}0\\0\\1\end{pmatrix} + c_3 e^{4t}\begin{pmatrix}1\\0\\1\end{pmatrix}, \end{gather*}
where \(c_1\text{,}\) \(c_2\text{,}\) and \(c_3\) are arbitrary constants.
Part (d): Nature of the solution space. Both eigenvalues are positive, so the origin is a completely unstable equilibrium and all non-trivial solutions diverge as \(t \to \infty\text{.}\) There are no stable lines or planes. The invariant structures are:
  • Unstable line along \(\mathbf{v}_3 = (1,0,1)^T\text{:}\) solutions with \(c_1 = c_2 = 0\) move along this line, growing like \(e^{4t}\text{.}\)
  • Unstable plane spanned by \(\mathbf{v}_1\) and \(\mathbf{v}_2\text{:}\) solutions with \(c_3 = 0\) remain in this plane and grow like \(e^{2t}\text{.}\) Because \(\lambda_1 = 2\) is semisimple, trajectories in this plane move along straight rays rather than curving (no Jordan block structure).
  • For generic initial conditions (\(c_3 \neq 0\)), the faster mode \(e^{4t}\) dominates and solutions diverge along directions asymptotically parallel to \(\mathbf{v}_3\text{.}\)

4.

\begin{equation*} A = \begin{pmatrix} 0 \amp -2 \amp -2 \\ 4 \amp 6 \amp -1 \\ 6 \amp 6 \amp -2 \end{pmatrix} \end{equation*}
Solution.
Part (a): Eigenvalues. The characteristic polynomial of
\begin{align*} A = \begin{pmatrix}0&-2&-2\\4&6&-1\\ 6&6&-2\end{pmatrix} \end{align*}
is
\begin{gather*} \det(A - \lambda I) = -(\lambda - 2)(\lambda^2 - 2\lambda + 10) = 0. \end{gather*}
The real eigenvalue is \(\lambda_1 = 2\text{,}\) and the quadratic gives the complex conjugate pair
\begin{gather*} \lambda_{2,3} = 1 \pm 3i. \end{gather*}
Part (b): Eigenvectors. For \(\lambda_1 = 2\text{:}\) solving \((A - 2I)\mathbf{v} = \mathbf{0}\text{,}\)
\begin{align*} \begin{pmatrix}-2&-2&-2\\4&4&-1\\ 6&6&-4\end{pmatrix}\mathbf{v} = \mathbf{0}, \end{align*}
the system reduces to \(v_3 = 0\) and \(v_1 = -v_2\text{,}\) giving
\begin{gather*} \mathbf{v}_1 = \begin{pmatrix}-1\\1\\0\end{pmatrix}. \end{gather*}
For \(\lambda_2 = 1 + 3i\text{:}\) solving \((A - (1+3i)I)\mathbf{v} = \mathbf{0}\) and taking \(v_3 = 2\) gives \(v_1 = 2i\) and \(v_2 = 1-i\text{,}\) so the complex eigenvector separates as
\begin{gather*} \mathbf{v}_2 = \begin{pmatrix}2i\\1-i\\2\end{pmatrix} = \underbrace{\begin{pmatrix}0\\1\\2\end{pmatrix}}_{\mathbf{p}} + i\underbrace{\begin{pmatrix}2\\-1\\0\end{pmatrix}}_{\mathbf{q}}, \end{gather*}
with \(\mathbf{v}_3 = \overline{\mathbf{v}_2}\text{.}\)
Part (c): General solution. The real eigenvalue \(\lambda_1 = 2\) gives a straight-line solution, and the complex pair \(\alpha \pm i\beta = 1 \pm 3i\) gives two real oscillatory solutions. The general solution is
\begin{align*} \mathbf{x}(t) &= c_1 e^{2t}\begin{pmatrix}-1\\1\\0\end{pmatrix}\\ &\quad + e^{t}\!\left[ c_2\!\left(\mathbf{p}\cos 3t - \mathbf{q}\sin 3t\right) + c_3\!\left(\mathbf{p}\sin 3t + \mathbf{q}\cos 3t\right) \right], \end{align*}
where
\begin{gather*} \mathbf{p} = \begin{pmatrix}0\\1\\2\end{pmatrix}, \qquad \mathbf{q} = \begin{pmatrix}2\\-1\\0\end{pmatrix}, \end{gather*}
and \(c_1\text{,}\) \(c_2\text{,}\) \(c_3\) are arbitrary constants.
Part (d): Nature of the solution space. All eigenvalues have positive real parts (\(\lambda_1 = 2 \gt 0\) and \(\operatorname{Re}(\lambda_{2,3}) = 1 \gt 0\)), so the origin is a completely unstable equilibrium. There are no stable lines or stable planes. The invariant structures are:
  • Unstable line along \(\mathbf{v}_1 = (-1,1,0)^T\text{:}\) solutions with \(c_2 = c_3 = 0\) move along this line, growing like \(e^{2t}\text{.}\)
  • Unstable spiraling plane spanned by \(\mathbf{p}\) and \(\mathbf{q}\text{:}\) solutions with \(c_1 = 0\) remain in this plane, spiraling outward with angular frequency \(\beta = 3\) while growing like \(e^{t}\text{.}\)
  • For generic initial conditions, all three modes grow and the solution diverges to infinity. The dominant mode is \(e^{2t}\text{,}\) so generic solutions eventually align asymptotically with the direction of \(\mathbf{v}_1\text{.}\)

5.

\begin{equation*} A = \begin{pmatrix} 11 \amp 14 \amp -9 \\ -5 \amp -8 \amp 7 \\ 4 \amp 4 \amp 2 \end{pmatrix} \end{equation*}
Solution.
Part (a): Eigenvalues. The characteristic polynomial of
\begin{align*} A = \begin{pmatrix}11&14&-9\\-5&-8&7\\ 4&4&2\end{pmatrix} \end{align*}
is
\begin{gather*} \det(A - \lambda I) = -(\lambda + 3)(\lambda^2 - 8\lambda + 20) = 0. \end{gather*}
The real eigenvalue is \(\lambda_1 = -3\text{,}\) and the quadratic gives the complex conjugate pair
\begin{gather*} \lambda_{2,3} = 4 \pm 2i. \end{gather*}
Part (b): Eigenvectors. For \(\lambda_1 = -3\text{:}\) solving \((A + 3I)\mathbf{v} = \mathbf{0}\text{,}\)
\begin{align*} \begin{pmatrix}14&14&-9\\-5&-5&7\\ 4&4&5\end{pmatrix}\mathbf{v} = \mathbf{0}. \end{align*}
The second and third rows together force \(v_3 = 0\text{,}\) after which all rows reduce to \(v_1 = -v_2\text{.}\) Taking \(v_2 = 1\text{,}\)
\begin{gather*} \mathbf{v}_1 = \begin{pmatrix}-1\\1\\0\end{pmatrix}. \end{gather*}
For \(\lambda_2 = 4 + 2i\text{:}\) solving \((A-(4+2i)I)\mathbf{v} = \mathbf{0}\) and taking \(v_3 = 2\) gives \(v_2 = 1 - i\) and \(v_1 = 2i\text{,}\) so the complex eigenvector separates as
\begin{gather*} \mathbf{v}_2 = \begin{pmatrix}2i\\1-i\\2\end{pmatrix} = \underbrace{\begin{pmatrix}0\\1\\2\end{pmatrix}}_{\mathbf{p}} + i\underbrace{\begin{pmatrix}2\\-1\\0\end{pmatrix}}_{\mathbf{q}}, \end{gather*}
with \(\mathbf{v}_3 = \overline{\mathbf{v}_2}\text{.}\)
Part (c): General solution. The real eigenvalue gives a decaying straight-line solution, and the complex pair \(\alpha \pm i\beta = 4 \pm 2i\) gives two real growing oscillatory solutions. The general solution is
\begin{align*} \mathbf{x}(t) &= c_1 e^{-3t}\begin{pmatrix}-1\\1\\0\end{pmatrix}\\ &\quad + e^{4t}\!\left[ c_2\!\left(\mathbf{p}\cos 2t - \mathbf{q}\sin 2t\right) + c_3\!\left(\mathbf{p}\sin 2t + \mathbf{q}\cos 2t\right) \right], \end{align*}
where
\begin{gather*} \mathbf{p} = \begin{pmatrix}0\\1\\2\end{pmatrix}, \qquad \mathbf{q} = \begin{pmatrix}2\\-1\\0\end{pmatrix}, \end{gather*}
and \(c_1\text{,}\) \(c_2\text{,}\) \(c_3\) are arbitrary constants.
Part (d): Nature of the solution space. The system has mixed stability:
  • \(\lambda_1 = -3 \lt 0\text{:}\) the eigenvector \(\mathbf{v}_1 = (-1,1,0)^T\) spans a stable line. Solutions with \(c_2 = c_3 = 0\) decay exponentially to the origin along this direction.
  • \(\lambda_{2,3} = 4 \pm 2i\text{:}\) the real part \(\alpha = 4 \gt 0\) means the complex modes grow. They span an unstable spiraling plane in the directions of \(\mathbf{p}\) and \(\mathbf{q}\text{,}\) with angular frequency \(\beta = 2\text{.}\)
  • For generic initial conditions (\(c_2^2 + c_3^2 \neq 0\)), the growing \(e^{4t}\) modes dominate and solutions spiral away from the origin. The stable line is the only direction in which solutions approach the origin; in all other directions solutions diverge. The origin is therefore a saddle in \(\mathbb{R}^3\text{.}\)
In summary, there is one stable line (along \(\mathbf{v}_1\)), one unstable spiraling plane (spanned by \(\mathbf{p}\) and \(\mathbf{q}\)), and no stable planes.

6.

\begin{equation*} A = \begin{pmatrix} 11 \amp 13 \amp -6 \\ -6 \amp -8 \amp 6 \\ 1 \amp -2 \amp 4 \end{pmatrix} \end{equation*}
Solution.
Part (a): Eigenvalues. The characteristic polynomial of
\begin{align*} A = \begin{pmatrix}11&13&-6\\-6&-8&6\\ 1&-2&4\end{pmatrix} \end{align*}
is
\begin{gather*} \det(A - \lambda I) = -(\lambda - 5)(\lambda^2 - 2\lambda + 10) = 0. \end{gather*}
The real eigenvalue is \(\lambda_1 = 5\text{,}\) and the quadratic gives the complex conjugate pair
\begin{gather*} \lambda_{2,3} = 1 \pm 3i. \end{gather*}
Part (b): Eigenvectors. For \(\lambda_1 = 5\text{:}\) solving \((A - 5I)\mathbf{v} = \mathbf{0}\text{,}\)
\begin{align*} \begin{pmatrix}6&13&-6\\-6&-13&6\\ 1&-2&-1\end{pmatrix}\mathbf{v} = \mathbf{0}. \end{align*}
Rows 1 and 2 are multiples; row 3 gives \(v_1 = v_3\) and substituting into row 1 forces \(v_2 = 0\text{.}\) Taking \(v_3 = 1\text{,}\)
\begin{gather*} \mathbf{v}_1 = \begin{pmatrix}1\\0\\1\end{pmatrix}. \end{gather*}
For \(\lambda_2 = 1 + 3i\text{:}\) solving \((A - (1+3i)I)\mathbf{v} = \mathbf{0}\) and taking \(v_3 = 1\) gives \(v_2 = 1 - i\) and \(v_1 = -1 + i\text{,}\) so the complex eigenvector separates as
\begin{gather*} \mathbf{v}_2 = \begin{pmatrix}-1+i\\1-i\\1\end{pmatrix} = \underbrace{\begin{pmatrix}-1\\1\\1\end{pmatrix}}_{\mathbf{p}} + i\underbrace{\begin{pmatrix}1\\-1\\0\end{pmatrix}}_{\mathbf{q}}, \end{gather*}
with \(\mathbf{v}_3 = \overline{\mathbf{v}_2}\text{.}\)
Part (c): General solution. The real eigenvalue gives a growing straight-line solution, and the complex pair \(\alpha \pm i\beta = 1 \pm 3i\) gives two real oscillatory solutions decaying slower than the real mode grows. The general solution is
\begin{align*} \mathbf{x}(t) &= c_1 e^{5t}\begin{pmatrix}1\\0\\1\end{pmatrix}\\ &\quad + e^{t}\!\left[ c_2\!\left(\mathbf{p}\cos 3t - \mathbf{q}\sin 3t\right) + c_3\!\left(\mathbf{p}\sin 3t + \mathbf{q}\cos 3t\right) \right], \end{align*}
where
\begin{gather*} \mathbf{p} = \begin{pmatrix}-1\\1\\1\end{pmatrix}, \qquad \mathbf{q} = \begin{pmatrix}1\\-1\\0\end{pmatrix}, \end{gather*}
and \(c_1\text{,}\) \(c_2\text{,}\) \(c_3\) are arbitrary constants.
Part (d): Nature of the solution space. All eigenvalues have positive real parts (\(\lambda_1 = 5 \gt 0\) and \(\operatorname{Re}(\lambda_{2,3}) = 1 \gt 0\)), so the origin is a completely unstable equilibrium and all non-trivial solutions diverge. There are no stable lines or stable planes. The invariant structures are:
  • Unstable line along \(\mathbf{v}_1 = (1,0,1)^T\text{:}\) solutions with \(c_2 = c_3 = 0\) move along this line, growing like \(e^{5t}\text{.}\)
  • Unstable spiraling plane spanned by \(\mathbf{p}\) and \(\mathbf{q}\text{:}\) solutions with \(c_1 = 0\) remain in this plane, spiraling outward with angular frequency \(\beta = 3\) while growing like \(e^{t}\text{.}\)
  • For generic initial conditions, the dominant mode is \(e^{5t}\text{,}\) so solutions eventually align asymptotically with \(\mathbf{v}_1\) as \(t \to \infty\text{.}\)

7.

\begin{equation*} A = \begin{pmatrix} 0 \amp 5 \amp 2 \\ 4 \amp -10 \amp -5 \\ -6 \amp 21 \amp 10 \end{pmatrix} \end{equation*}
Solution.
Part (a): Eigenvalues. The characteristic polynomial of
\begin{align*} A = \begin{pmatrix}0&5&2\\4&-10&-5\\ -6&21&10\end{pmatrix} \end{align*}
is
\begin{gather*} \det(A - \lambda I) = -(\lambda - 1)^2(\lambda + 2) = 0, \end{gather*}
giving eigenvalues
\begin{gather*} \lambda_1 = 1 \text{ (multiplicity 2)}, \qquad \lambda_2 = -2 \text{ (multiplicity 1)}. \end{gather*}
Part (b): Eigenvectors. For \(\lambda_1 = 1\text{:}\) solving \((A - I)\mathbf{v} = \mathbf{0}\text{,}\)
\begin{align*} \begin{pmatrix}-1&5&2\\4&-11&-5\\ -6&21&9\end{pmatrix}\mathbf{v} = \mathbf{0}. \end{align*}
Row reduction gives rank 2, so the nullity is 1 and \(\lambda_1 = 1\) is defective. The single eigenvector is
\begin{gather*} \mathbf{v}_1 = \begin{pmatrix}-1\\1\\-3\end{pmatrix}. \end{gather*}
A generalized eigenvector satisfying \((A - I)\mathbf{w} = \mathbf{v}_1\) is found from
\begin{align*} \begin{pmatrix}-1&5&2\\4&-11&-5\\ -6&21&9\end{pmatrix}\mathbf{w} = \begin{pmatrix}-1\\1\\-3\end{pmatrix} \implies \mathbf{w} = \begin{pmatrix}-1\\0\\-1\end{pmatrix}. \end{align*}
For \(\lambda_2 = -2\text{:}\) solving \((A + 2I)\mathbf{v} = \mathbf{0}\text{,}\)
\begin{align*} \begin{pmatrix}2&5&2\\4&-8&-5\\ -6&21&12\end{pmatrix}\mathbf{v} = \mathbf{0} \implies \mathbf{v}_2 = \begin{pmatrix}-1\\2\\-4\end{pmatrix}. \end{align*}
Part (c): General solution. The defective eigenvalue \(\lambda_1 = 1\) contributes a straight-line solution and a generalized solution; the simple eigenvalue \(\lambda_2 = -2\) contributes a decaying solution. The general solution is
\begin{align*} \mathbf{x}(t) \amp = c_1 e^{t}\begin{pmatrix}-1\\1\\-3\end{pmatrix} + c_2 e^{t}\!\left(t\begin{pmatrix}-1\\1\\-3\end{pmatrix} + \begin{pmatrix}-1\\0\\-1\end{pmatrix}\right) + c_3 e^{-2t}\begin{pmatrix}-1\\2\\-4\end{pmatrix}, \end{align*}
where \(c_1\text{,}\) \(c_2\text{,}\) \(c_3\) are arbitrary constants.
Part (d): Nature of the solution space. The system has mixed stability:
  • \(\lambda_2 = -2 \lt 0\text{:}\) the eigenvector \(\mathbf{v}_2 = (-1,2,-4)^T\) spans a stable line. Solutions with \(c_1 = c_2 = 0\) decay to the origin like \(e^{-2t}\text{.}\)
  • \(\lambda_1 = 1 \gt 0\) (defective): the eigenvector \(\mathbf{v}_1\) spans an unstable line, and the generalized eigenvector \(\mathbf{w}\) together with \(\mathbf{v}_1\) spans an unstable plane. Solutions in this plane grow like \(te^{t}\) (from the Jordan block) rather than pure exponentials, so they diverge faster than a non-defective unstable node would.
  • For generic initial conditions (\(c_2 \neq 0\)), the \(te^{t}\) term dominates for large \(t\) and solutions diverge in the direction of \(\mathbf{v}_1\text{.}\)
In summary, there is one stable line (along \(\mathbf{v}_2\)), one unstable plane (spanned by \(\mathbf{v}_1\) and \(\mathbf{w}\)), and no stable planes.

8.

\begin{equation*} A = \begin{pmatrix} 5 \amp 7 \amp -1 \\ -1 \amp -3 \amp 1 \\ 6 \amp 6 \amp -2 \end{pmatrix} \end{equation*}
Solution.
Part (a): Eigenvalues. The characteristic polynomial of
\begin{align*} A = \begin{pmatrix}5&7&-1\\-1&-3&1\\ 6&6&-2\end{pmatrix} \end{align*}
is
\begin{gather*} \det(A - \lambda I) = -(\lambda + 2)^2(\lambda - 4) = 0, \end{gather*}
giving eigenvalues
\begin{gather*} \lambda_1 = -2 \text{ (multiplicity 2)}, \qquad \lambda_2 = 4 \text{ (multiplicity 1)}. \end{gather*}
Part (b): Eigenvectors. For \(\lambda_1 = -2\text{:}\) solving \((A + 2I)\mathbf{v} = \mathbf{0}\text{,}\)
\begin{align*} \begin{pmatrix}7&7&-1\\-1&-1&1\\ 6&6&0\end{pmatrix}\mathbf{v} = \mathbf{0}. \end{align*}
Row reduction gives rank 2, so the nullity is 1 and \(\lambda_1 = -2\) is defective. The single eigenvector is
\begin{gather*} \mathbf{v}_1 = \begin{pmatrix}-1\\1\\0\end{pmatrix}. \end{gather*}
A generalized eigenvector satisfying \((A + 2I)\mathbf{w} = \mathbf{v}_1\) is found from
\begin{align*} \begin{pmatrix}7&7&-1\\-1&-1&1\\ 6&6&0\end{pmatrix}\mathbf{w} = \begin{pmatrix}-1\\1\\0\end{pmatrix} \implies \mathbf{w} = \begin{pmatrix}0\\0\\1\end{pmatrix}. \end{align*}
For \(\lambda_2 = 4\text{:}\) solving \((A - 4I)\mathbf{v} = \mathbf{0}\text{,}\)
\begin{align*} \begin{pmatrix}1&7&-1\\-1&-7&1\\ 6&6&-6\end{pmatrix}\mathbf{v} = \mathbf{0} \implies \mathbf{v}_2 = \begin{pmatrix}1\\0\\1\end{pmatrix}. \end{align*}
Part (c): General solution. The defective eigenvalue \(\lambda_1 = -2\) contributes a decaying straight-line solution and a generalized decaying solution; the simple eigenvalue \(\lambda_2 = 4\) contributes a growing solution. The general solution is
\begin{gather*} \mathbf{x}(t) = c_1 e^{-2t}\begin{pmatrix}-1\\1\\0\end{pmatrix} + c_2 e^{-2t}\!\left(t\begin{pmatrix}-1\\1\\0\end{pmatrix} + \begin{pmatrix}0\\0\\1\end{pmatrix}\right) + c_3 e^{4t}\begin{pmatrix}1\\0\\1\end{pmatrix}, \end{gather*}
where \(c_1\text{,}\) \(c_2\text{,}\) \(c_3\) are arbitrary constants.
Part (d): Nature of the solution space. The system has mixed stability:
  • \(\lambda_1 = -2 \lt 0\) (defective): the eigenvector \(\mathbf{v}_1 = (-1,1,0)^T\) spans a stable line. Solutions on this line decay like \(e^{-2t}\text{.}\) The generalized eigenvector \(\mathbf{w}\) together with \(\mathbf{v}_1\) spans a stable plane: solutions with \(c_3 = 0\) decay to the origin (the \(te^{-2t}\) term still decays since \(te^{-2t} \to 0\)), though more slowly than those on the stable line alone.
  • \(\lambda_2 = 4 \gt 0\text{:}\) the eigenvector \(\mathbf{v}_2 = (1,0,1)^T\) spans an unstable line. Solutions with \(c_1 = c_2 = 0\) grow like \(e^{4t}\text{.}\)
  • For generic initial conditions (\(c_3 \neq 0\)), the growing mode \(e^{4t}\) dominates and solutions diverge along the direction of \(\mathbf{v}_2\text{.}\) The origin is a saddle in \(\mathbb{R}^3\text{.}\)
In summary, there is one stable plane (spanned by \(\mathbf{v}_1\) and \(\mathbf{w}\)), one stable line (along \(\mathbf{v}_1\)), and one unstable line (along \(\mathbf{v}_2\)).

Solving Initial-Value Problems \(3 \times 3\) Systems.

Solve each of initial-value problems in Exercise Group 3.8.6.9–16

9.

\begin{align*} x' \amp = 4x + 3y - z\\ y' \amp = -x - z\\ z' \amp = x + y + 2z\\ x(0) \amp = -1\\ y(0) \amp = 1\\ z(0) \amp = 0 \end{align*}
Solution.
Writing the system in matrix form \(\mathbf{x}' = A\mathbf{x}\) with
\begin{align*} A = \begin{pmatrix}4&3&-1\\-1&0&-1\\ 1&1&2\end{pmatrix}, \qquad \mathbf{x}(0) = \begin{pmatrix}-1\\1\\0\end{pmatrix}, \end{align*}
the characteristic polynomial is
\begin{gather*} \det(A - \lambda I) = -(\lambda-1)(\lambda^2 - 5\lambda + 8) = 0, \end{gather*}
giving real eigenvalue \(\lambda_1 = 1\) and complex pair \(\lambda_{2,3} = \tfrac{5 \pm i\sqrt{7}}{2}\text{.}\) For \(\lambda_1 = 1\text{,}\) solving \((A - I)\mathbf{v} = \mathbf{0}\) gives the eigenvector
\begin{gather*} \mathbf{v}_1 = \begin{pmatrix}-1\\1\\0\end{pmatrix}. \end{gather*}
We observe that the initial condition satisfies
\begin{gather*} \mathbf{x}(0) = \begin{pmatrix}-1\\1\\0\end{pmatrix} = 1 \cdot \mathbf{v}_1, \end{gather*}
so the initial condition lies exactly on the stable straight-line solution corresponding to \(\lambda_1 = 1\text{.}\) Therefore \(c_1 = 1\) and \(c_2 = c_3 = 0\text{,}\) and the solution is
\begin{gather*} \mathbf{x}(t) = e^{t}\begin{pmatrix}-1\\1\\0\end{pmatrix}, \end{gather*}
i.e.,
\begin{align*} x(t) &= -e^{t},\\ y(t) &= e^{t},\\ z(t) &= 0. \end{align*}
We verify: \(x' = -e^t\) and \(4x + 3y - z = -4e^t + 3e^t = -e^t\) ✓; \(y' = e^t\) and \(-x - z = e^t\) ✓; \(z' = 0\) and \(x + y + 2z = -e^t + e^t = 0\) ✓. The initial conditions \(x(0) = -1\text{,}\) \(y(0) = 1\text{,}\) \(z(0) = 0\) are also satisfied. Since \(\lambda_1 = 1 \gt 0\text{,}\) the solution grows exponentially and diverges from the origin as \(t \to \infty\text{.}\)

10.

\begin{align*} x' \amp = -2x - 3y + 4z\\ y' \amp = 4x + 5y - 4z\\ z' \amp = 5x + 5y - 3z\\ x(0) \amp = 2\\ y(0) \amp = -1\\ z(0) \amp = -1 \end{align*}
Solution.
Writing the system in matrix form \(\mathbf{x}' = A\mathbf{x}\) with
\begin{align*} A = \begin{pmatrix}-2&-3&4\\4&5&-4\\ 5&5&-3\end{pmatrix}, \qquad \mathbf{x}(0) = \begin{pmatrix}2\\-1\\-1\end{pmatrix}. \end{align*}
The characteristic polynomial is
\begin{gather*} \det(A - \lambda I) = -(\lambda-1)(\lambda-2)(\lambda+3) = 0, \end{gather*}
giving eigenvalues \(\lambda_1 = 1\text{,}\) \(\lambda_2 = 2\text{,}\) \(\lambda_3 = -3\) with corresponding eigenvectors
\begin{gather*} \mathbf{v}_1 = \begin{pmatrix}-1\\1\\0\end{pmatrix}, \qquad \mathbf{v}_2 = \begin{pmatrix}1\\0\\1\end{pmatrix}, \qquad \mathbf{v}_3 = \begin{pmatrix}-1\\1\\1\end{pmatrix}. \end{gather*}
The general solution is
\begin{gather*} \mathbf{x}(t) = c_1 e^{t}\begin{pmatrix}-1\\1\\0\end{pmatrix} + c_2 e^{2t}\begin{pmatrix}1\\0\\1\end{pmatrix} + c_3 e^{-3t}\begin{pmatrix}-1\\1\\1\end{pmatrix}. \end{gather*}
Applying the initial condition \(c_1\mathbf{v}_1 + c_2\mathbf{v}_2 + c_3\mathbf{v}_3 = (2,-1,-1)^T\) gives the system
\begin{align*} -c_1 + c_2 - c_3 &= 2,\\ c_1 \phantom{{}+ c_2{}} + c_3 &= -1,\\ c_2 + c_3 &= -1. \end{align*}
From the third equation \(c_2 = -1 - c_3\text{;}\) from the second \(c_1 = -1 - c_3\text{;}\) substituting into the first gives \(c_3 = -2\text{,}\) then \(c_1 = 1\) and \(c_2 = 1\text{.}\) The solution is
\begin{gather*} \mathbf{x}(t) = e^{t}\begin{pmatrix}-1\\1\\0\end{pmatrix} + e^{2t}\begin{pmatrix}1\\0\\1\end{pmatrix} - 2e^{-3t}\begin{pmatrix}-1\\1\\1\end{pmatrix}, \end{gather*}
i.e.,
\begin{align*} x(t) &= -e^{t} + e^{2t} + 2e^{-3t},\\ y(t) &= e^{t} - 2e^{-3t},\\ z(t) &= e^{2t} - 2e^{-3t}. \end{align*}
As \(t \to \infty\) the dominant term is \(e^{2t}\text{,}\) so the solution diverges. As \(t \to -\infty\) the dominant term is \(e^{-3t}\text{.}\)

11.

\begin{align*} x' \amp = 4x + 2y\\ y' \amp = 2y\\ z' \amp = 2x + 2y + 2z\\ x(0) \amp = 1\\ y(0) \amp = 1\\ z(0) \amp = 1 \end{align*}
Solution.
Writing the system in matrix form \(\mathbf{x}' = A\mathbf{x}\) with
\begin{align*} A = \begin{pmatrix}4&2&0\\0&2&0\\ 2&2&2\end{pmatrix}, \qquad \mathbf{x}(0) = \begin{pmatrix}1\\1\\1\end{pmatrix}. \end{align*}
The characteristic polynomial is
\begin{gather*} \det(A - \lambda I) = -(2-\lambda)^2(4-\lambda) = 0, \end{gather*}
giving eigenvalue \(\lambda_1 = 2\) (algebraic multiplicity 2, semisimple) with two independent eigenvectors, and \(\lambda_2 = 4\text{:}\)
\begin{gather*} \mathbf{v}_1 = \begin{pmatrix}-1\\1\\0\end{pmatrix}, \qquad \mathbf{v}_2 = \begin{pmatrix}0\\0\\1\end{pmatrix}, \qquad \mathbf{v}_3 = \begin{pmatrix}1\\0\\1\end{pmatrix}. \end{gather*}
The general solution is
\begin{gather*} \mathbf{x}(t) = c_1 e^{2t}\begin{pmatrix}-1\\1\\0\end{pmatrix} + c_2 e^{2t}\begin{pmatrix}0\\0\\1\end{pmatrix} + c_3 e^{4t}\begin{pmatrix}1\\0\\1\end{pmatrix}. \end{gather*}
Applying the initial condition \(c_1\mathbf{v}_1 + c_2\mathbf{v}_2 + c_3\mathbf{v}_3 = (1,1,1)^T\) gives the system
\begin{align*} -c_1 + c_3 &= 1,\\ c_1 &= 1,\\ c_2 + c_3 &= 1. \end{align*}
From the second equation \(c_1 = 1\text{;}\) from the first \(c_3 = 2\text{;}\) from the third \(c_2 = -1\text{.}\) The solution is
\begin{gather*} \mathbf{x}(t) = e^{2t}\begin{pmatrix}-1\\1\\0\end{pmatrix} - e^{2t}\begin{pmatrix}0\\0\\1\end{pmatrix} + 2e^{4t}\begin{pmatrix}1\\0\\1\end{pmatrix}, \end{gather*}
i.e.,
\begin{align*} x(t) &= -e^{2t} + 2e^{4t},\\ y(t) &= e^{2t},\\ z(t) &= -e^{2t} + 2e^{4t}. \end{align*}
Since both eigenvalues are positive, the solution grows without bound as \(t \to \infty\text{,}\) with the \(e^{4t}\) term dominating.

12.

\begin{align*} x' \amp = -2y - 2z\\ y' \amp = 4x + 6y - z\\ z' \amp = 6x + 6y - 2z\\ x(0) \amp = 1\\ y(0) \amp = 2\\ z(0) \amp = 3 \end{align*}
Solution.
Writing the system in matrix form \(\mathbf{x}' = A\mathbf{x}\) with
\begin{align*} A = \begin{pmatrix}0&-2&-2\\4&6&-1\\ 6&6&-2\end{pmatrix}, \qquad \mathbf{x}(0) = \begin{pmatrix}1\\2\\3\end{pmatrix}. \end{align*}
The characteristic polynomial is
\begin{gather*} \det(A - \lambda I) = -(\lambda-2)(\lambda^2-2\lambda+10) = 0, \end{gather*}
giving real eigenvalue \(\lambda_1 = 2\) with eigenvector
\begin{gather*} \mathbf{v}_1 = \begin{pmatrix}-1\\1\\0\end{pmatrix}, \end{gather*}
and complex pair \(\lambda_{2,3} = 1 \pm 3i\) with
\begin{gather*} \mathbf{p} = \begin{pmatrix}0\\1\\2\end{pmatrix}, \qquad \mathbf{q} = \begin{pmatrix}2\\-1\\0\end{pmatrix}. \end{gather*}
The general solution is
\begin{align*} \mathbf{x}(t) &= c_1 e^{2t}\begin{pmatrix}-1\\1\\0\end{pmatrix}\\ &\quad + e^{t}\!\left[ c_2\!\left(\mathbf{p}\cos 3t - \mathbf{q}\sin 3t\right) + c_3\!\left(\mathbf{p}\sin 3t + \mathbf{q}\cos 3t\right) \right]. \end{align*}
Writing out components and applying \(\mathbf{x}(0) = (1,2,3)^T\text{:}\)
\begin{align*} x(0) = -c_1 + 2c_3 &= 1,\\ y(0) = c_1 + c_2 - c_3 &= 2,\\ z(0) = 2c_2 &= 3. \end{align*}
From the third equation \(c_2 = \tfrac{3}{2}\text{;}\) from the first \(c_1 = 2c_3 - 1\text{;}\) substituting into the second gives \(c_3 = \tfrac{3}{2}\) and then \(c_1 = 2\text{.}\) The solution is
\begin{align*} x(t) &= -2e^{2t} + 3e^{t}(\cos 3t - \sin 3t),\\ y(t) &= 2e^{2t} + 3e^{t}\sin 3t,\\ z(t) &= 3e^{t}(\cos 3t + \sin 3t). \end{align*}
Since \(\operatorname{Re}(\lambda_{2,3}) = 1 \gt 0\) and \(\lambda_1 = 2 \gt 0\text{,}\) all modes grow and the solution diverges as \(t \to \infty\text{,}\) with the \(e^{2t}\) term eventually dominating.

13.

\begin{align*} x' \amp = 11x + 14y - 9z\\ y' \amp = -5x - 8y + 7z\\ z' \amp = 4x + 4y + 2z\\ x(0) \amp = -1\\ y(0) \amp = -2\\ z(0) \amp = -3 \end{align*}
Solution.
Writing the system in matrix form \(\mathbf{x}' = A\mathbf{x}\) with
\begin{align*} A = \begin{pmatrix}11&14&-9\\-5&-8&7\\ 4&4&2\end{pmatrix}, \qquad \mathbf{x}(0) = \begin{pmatrix}-1\\-2\\-3\end{pmatrix}. \end{align*}
The characteristic polynomial is
\begin{gather*} \det(A - \lambda I) = -(\lambda+3)(\lambda^2 - 8\lambda + 20) = 0, \end{gather*}
giving real eigenvalue \(\lambda_1 = -3\) with eigenvector
\begin{gather*} \mathbf{v}_1 = \begin{pmatrix}-1\\1\\0\end{pmatrix}, \end{gather*}
and complex pair \(\lambda_{2,3} = 4 \pm 2i\) with
\begin{gather*} \mathbf{p} = \begin{pmatrix}0\\1\\2\end{pmatrix}, \qquad \mathbf{q} = \begin{pmatrix}2\\-1\\0\end{pmatrix}. \end{gather*}
The general solution is
\begin{align*} \mathbf{x}(t) &= c_1 e^{-3t}\begin{pmatrix}-1\\1\\0\end{pmatrix}\\ &\quad + e^{4t}\!\left[ c_2\!\left(\mathbf{p}\cos 2t - \mathbf{q}\sin 2t\right) + c_3\!\left(\mathbf{p}\sin 2t + \mathbf{q}\cos 2t\right) \right]. \end{align*}
Writing out components and applying \(\mathbf{x}(0) = (-1,-2,-3)^T\text{:}\)
\begin{align*} x(0) = -c_1 + 2c_3 &= -1,\\ y(0) = c_1 + c_2 - c_3 &= -2,\\ z(0) = 2c_2 &= -3. \end{align*}
From the third equation \(c_2 = -\tfrac{3}{2}\text{;}\) from the first \(c_1 = 2c_3 + 1\text{;}\) substituting into the second gives \(c_3 = -\tfrac{3}{2}\) and then \(c_1 = -2\text{.}\) The solution is
\begin{align*} x(t) &= 2e^{-3t} - 3e^{4t}(\cos 2t - \sin 2t),\\ y(t) &= -2e^{-3t} - 3e^{4t}\sin 2t,\\ z(t) &= -3e^{4t}(\cos 2t + \sin 2t). \end{align*}
Since \(\lambda_1 = -3 \lt 0\) the first term decays, but \(\operatorname{Re}(\lambda_{2,3}) = 4 \gt 0\) so the oscillating \(e^{4t}\) modes grow and dominate as \(t \to \infty\text{.}\)

14.

\begin{align*} x' \amp = 11x + 13y - 6z\\ y' \amp = -6x - 8y + 6z\\ z' \amp = x - 2y + 4z\\ x(0) \amp = -2\\ y(0) \amp = 2\\ z(0) \amp = 0 \end{align*}
Solution.
Writing the system in matrix form \(\mathbf{x}' = A\mathbf{x}\) with
\begin{align*} A = \begin{pmatrix}11&13&-6\\-6&-8&6\\ 1&-2&4\end{pmatrix}, \qquad \mathbf{x}(0) = \begin{pmatrix}-2\\2\\0\end{pmatrix}. \end{align*}
The characteristic polynomial is
\begin{gather*} \det(A - \lambda I) = -(\lambda-5)(\lambda^2 - 2\lambda + 10) = 0, \end{gather*}
giving real eigenvalue \(\lambda_1 = 5\) with eigenvector
\begin{gather*} \mathbf{v}_1 = \begin{pmatrix}1\\0\\1\end{pmatrix}, \end{gather*}
and complex pair \(\lambda_{2,3} = 1 \pm 3i\) with
\begin{gather*} \mathbf{p} = \begin{pmatrix}-1\\1\\1\end{pmatrix}, \qquad \mathbf{q} = \begin{pmatrix}1\\-1\\0\end{pmatrix}. \end{gather*}
The general solution is
\begin{align*} \mathbf{x}(t) &= c_1 e^{5t}\begin{pmatrix}1\\0\\1\end{pmatrix}\\ &\quad + e^{t}\!\left[ c_2\!\left(\mathbf{p}\cos 3t - \mathbf{q}\sin 3t\right) + c_3\!\left(\mathbf{p}\sin 3t + \mathbf{q}\cos 3t\right) \right]. \end{align*}
Writing out components and applying \(\mathbf{x}(0) = (-2,2,0)^T\text{:}\)
\begin{align*} x(0) = c_1 - c_2 + c_3 &= -2,\\ y(0) = c_2 - c_3 &= 2,\\ z(0) = c_2 &= 0. \end{align*}
From the third equation \(c_2 = 0\text{;}\) from the second \(c_3 = -2\text{;}\) from the first \(c_1 = 0\text{.}\) The solution is
\begin{gather*} \mathbf{x}(t) = -2e^{t}\!\left(\mathbf{p}\sin 3t + \mathbf{q}\cos 3t\right), \end{gather*}
i.e.,
\begin{align*} x(t) &= e^{t}(2\sin 3t - 2\cos 3t),\\ y(t) &= e^{t}(-2\sin 3t + 2\cos 3t),\\ z(t) &= -2e^{t}\sin 3t. \end{align*}
Since \(c_1 = 0\) the \(e^{5t}\) mode is absent; the solution is purely oscillatory with exponentially growing amplitude governed by \(\operatorname{Re}(\lambda_{2,3}) = 1 \gt 0\text{,}\) so it diverges as \(t \to \infty\text{.}\)

15.

\begin{align*} x' \amp = 5y + 2z\\ y' \amp = 4x - 10y - 5z\\ z' \amp = -6x + 21y + 10z\\ x(0) \amp = 1\\ y(0) \amp = 1\\ z(0) \amp = 3 \end{align*}
Solution.
Writing the system in matrix form \(\mathbf{x}' = A\mathbf{x}\) with
\begin{align*} A = \begin{pmatrix}0&5&2\\4&-10&-5\\ -6&21&10\end{pmatrix}, \qquad \mathbf{x}(0) = \begin{pmatrix}1\\1\\3\end{pmatrix}. \end{align*}
The characteristic polynomial is
\begin{gather*} \det(A - \lambda I) = -(\lambda-1)^2(\lambda+2) = 0, \end{gather*}
giving defective eigenvalue \(\lambda_1 = 1\) (multiplicity 2) with eigenvector \(\mathbf{v}_1 = (-1,1,-3)^T\) and generalized eigenvector \(\mathbf{w} = (-1,0,-1)^T\text{,}\) and simple eigenvalue \(\lambda_2 = -2\) with eigenvector \(\mathbf{v}_2 = (-1,2,-4)^T\text{.}\) The general solution is
\begin{gather*} \mathbf{x}(t) = c_1 e^{t}\begin{pmatrix}-1\\1\\-3\end{pmatrix} \\ + c_2 e^{t}\!\left(t\begin{pmatrix}-1\\1\\-3\end{pmatrix} + \begin{pmatrix}-1\\0\\-1\end{pmatrix}\right) + c_3 e^{-2t}\begin{pmatrix}-1\\2\\-4\end{pmatrix}. \end{gather*}
Applying the initial condition \(\mathbf{x}(0) = (1,1,3)^T\text{:}\)
\begin{align*} -c_1 - c_2 - c_3 &= 1,\\ c_1 + 2c_3 &= 1,\\ -3c_1 - c_2 - 4c_3 &= 3. \end{align*}
From the second equation \(c_1 = 1 - 2c_3\text{;}\) substituting into the first gives \(c_2 = c_3 - 2\text{;}\) substituting both into the third gives \(c_3 = 4\text{,}\) then \(c_2 = 2\) and \(c_1 = -7\text{.}\) The solution is
\begin{align*} x(t) &= e^{t}(5 - 2t) - 4e^{-2t},\\ y(t) &= e^{t}(-7 + 2t) + 8e^{-2t},\\ z(t) &= e^{t}(19 - 6t) - 16e^{-2t}. \end{align*}
Since \(\lambda_1 = 1 \gt 0\) and the \(te^t\) terms grow without bound, the solution diverges as \(t \to \infty\text{.}\) The \(e^{-2t}\) mode decays and becomes negligible for large \(t\text{.}\)

16.

\begin{align*} x' \amp = 5x + 7y - z\\ y' \amp = -x - 3y + z\\ z' \amp = 6x + 6y - 2z\\ x(0) \amp = -1\\ y(0) \amp = 0\\ z(0) \amp = 2 \end{align*}
Solution.
Writing the system in matrix form \(\mathbf{x}' = A\mathbf{x}\) with
\begin{align*} A = \begin{pmatrix}5&7&-1\\-1&-3&1\\ 6&6&-2\end{pmatrix}, \qquad \mathbf{x}(0) = \begin{pmatrix}-1\\0\\2\end{pmatrix}. \end{align*}
The characteristic polynomial is
\begin{gather*} \det(A - \lambda I) = -(\lambda+2)^2(\lambda-4) = 0, \end{gather*}
giving defective eigenvalue \(\lambda_1 = -2\) (multiplicity 2) with eigenvector \(\mathbf{v}_1 = (-1,1,0)^T\) and generalized eigenvector \(\mathbf{w} = (0,0,1)^T\text{,}\) and simple eigenvalue \(\lambda_2 = 4\) with eigenvector \(\mathbf{v}_2 = (1,0,1)^T\text{.}\) The general solution is
\begin{gather*} \mathbf{x}(t) = c_1 e^{-2t}\begin{pmatrix}-1\\1\\0\end{pmatrix}\\ + c_2 e^{-2t}\!\left(t\begin{pmatrix}-1\\1\\0\end{pmatrix} + \begin{pmatrix}0\\0\\1\end{pmatrix}\right) + c_3 e^{4t}\begin{pmatrix}1\\0\\1\end{pmatrix}. \end{gather*}
Applying the initial condition \(\mathbf{x}(0) = (-1,0,2)^T\text{:}\)
\begin{align*} -c_1 + c_3 &= -1,\\ c_1 &= 0,\\ c_2 + c_3 &= 2. \end{align*}
From the second equation \(c_1 = 0\text{;}\) from the first \(c_3 = -1\text{;}\) from the third \(c_2 = 3\text{.}\) The solution is
\begin{align*} x(t) &= -3te^{-2t} - e^{4t},\\ y(t) &= 3te^{-2t},\\ z(t) &= 3e^{-2t} - e^{4t}. \end{align*}
Since \(\lambda_2 = 4 \gt 0\text{,}\) the \(e^{4t}\) mode grows and dominates as \(t \to \infty\text{.}\) The defective \(e^{-2t}\) modes (including the \(te^{-2t}\) term) decay to zero since \(te^{-2t} \to 0\) as \(t \to \infty\text{.}\)
You have attempted of activities on this page.