To understand that the characteristic polynomial of a \(2 \times 2\) matrix can be written as
\begin{equation*}
\lambda^2 - T \lambda + D,
\end{equation*}
where \(T = \trace(A)\) and \(D = \det(A)\text{.}\) Furthermore, if a \(2 \times 2\) matrix \(A\) has eigenvalues \(\lambda_1\) and \(\lambda_2\text{,}\) then \(\trace(A)\) is \(\lambda_1 + \lambda_2\) and \(\det(A) = \lambda_1 \lambda_2\text{,}\) and the trace and determinant of a \(2 \times 2\) matrix are invariant under a change of coordinates.
To understand that the trace-determinant plane is determined by the graph of the parabola \(D= T^2/4\) on the \(TD\)-plane and that the trace-determinant plane can be used to determine the phase portrait of a linear system.
Suppose that we have two tanks, Tank \(A\) and Tank \(B\text{,}\) that both have a volume of \(V\) liters and are both filled with a brine solution. Suppose that pure water enters Tank \(A\) at a rate of \(r_{\text{in}}\) liters per minute, and a salt mixture enters Tank \(A\) from Tank \(B\) at a rate of \(r_B\) liters per minute. Brine also enters Tank \(B\) from Tank \(A\) at a rate of \(r_A\) liters per minute. Finally, brine is drained from Tank \(B\) at a rate of \(r_{\text{out}}\) so that the volume in each tank is constant (Figure 3.7.1).
If \(x(t)\) and \(y(t)\) are the amounts of salt in Tank \(A\) and Tank \(B\text{,}\) respectively, then our problem can be modeled with a linear system of two equations,
If we have initial conditions \(x(0) = x_0\) and \(y(0) = y_0\text{,}\) it is not too difficult to deduce that the amount of salt in each tank will approach zero as \(t \to \infty\text{,}\) and we will have a stable equilibrium solution at \((0, 0)\text{.}\) Determining the nature of the equilibrium solution is a more difficult question. For example, is it ever possible that the equilibrium solution is a spiral sink? One solution is provided by studying the trace-determinant plane.
\begin{equation*}
\begin{pmatrix}
x' \\ y'
\end{pmatrix}
=
\begin{pmatrix}
a & b \\
c & d
\end{pmatrix}
\begin{pmatrix}
x \\ y
\end{pmatrix}
=
A
\begin{pmatrix}
x \\ y
\end{pmatrix}
\end{equation*}
is determining the eigenvalues of \(A\text{.}\) To find these eigenvalues, we need to derive the characteristic polynomial of \(A\text{,}\)
\begin{equation*}
\det(A - \lambda I)
=
\det
\begin{pmatrix}
a - \lambda & b \\
c & d - \lambda
\end{pmatrix}
=
\lambda^2 - (a + d) \lambda + (ad - bc).
\end{equation*}
Of course, \(D = \det(A) = ad -bc\) is the determinant of \(A\text{.}\) The quantity \(T = a + d\) is the sum of the diagonal elements of the matrix \(A\text{.}\) We call this quantity the trace of \(A\) and write \(\trace(A)\text{.}\) Thus, we can rewrite the characteristic polynomial as
\begin{equation*}
\det(A - \lambda I) = \lambda^2 - T \lambda + D.
\end{equation*}
We can use the trace and determinant to establish the nature of a solution to a linear system.
If a \(2 \times 2\) matrix \(A\) has eigenvalues \(\lambda_1\) and \(\lambda_2\text{,}\) then the trace of \(A\) is \(\lambda_1 + \lambda_2\) and \(\det(A) = \lambda_1 \lambda_2\text{.}\)
Theorem 3.7.2 tells us that we can determine the determinant and trace of a \(2 \times 2\) matrix from its eigenvalues. Thus, we should be able to determine the phase portrait of a system \({\mathbf x}' = A {\mathbf x}\) by simply examining the trace and determinant of \(A\text{.}\) Since the eigenvalues of \(A\) are given by
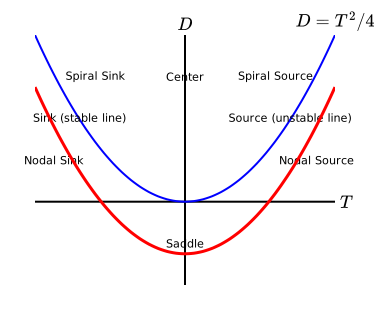
If \(T^2 - 4D = 0\) or equivalently if \(D = T^2/4\text{,}\) we have repeated eigenvalues. In fact, we can represent those systems with repeated eigenvalues by graphing the parabola \(D= T^2/4\) on the \(TD\)-plane or trace-determinant plane (Figure 3.7.3). Therefore, points on the parabola correspond to systems with repeated eigenvalues, points above the parabola (\(D \gt T^2/4\) or equivalently \(T^2 - 4D \lt 0\)) correspond to systems with complex eigenvalues, and points below the parabola (\(D \lt T^2/4\) or equivalently \(T^2 - 4D \gt 0\)) correspond to systems with real eigenvalues.
The trace and determinant of a \(2 \times 2\) matrix are invariant under a change of coordinates. That is, \(\det(T^{-1} A T) = \det(A)\) and \(\trace(T^{-1} A T) = \trace(A)\) for any \(2 \times 2\) matrix \(A\) and any invertible \(2 \times 2\) matrix \(T\text{.}\)
It is straightforward to verify that \(\det(AB) = \det(A) \det(B)\) and \(\det(T^{-1}) = 1/\det(T)\) for \(2 \times 2\) matrices \(A\) and \(B\text{.}\) Therefore,
Furthermore, the expression \(T^2 - 4D\) is not affected by a change of coordinates by Theorem 3.7.4. That is, we only need to consider systems \({\mathbf x}' = A {\mathbf x}\text{,}\) where \(A\) is one of the following matrices:
has eigenvalues \(\lambda = \alpha \pm i \beta\text{.}\) The general solution to this system is
\begin{equation*}
{\mathbf x}(t)
=
c_1
e^{\alpha t}
\begin{pmatrix}
\cos \beta t \\ - \sin \beta t
\end{pmatrix}
+
c_2 e^{\alpha t}
\begin{pmatrix}
\sin \beta t \\ \cos \beta t
\end{pmatrix}.
\end{equation*}
The \(e^{\alpha t}\) factor tells us that the solutions either spiral into the origin if \(\alpha \lt 0\text{,}\) spiral out to infinity if \(\alpha \gt 0\text{,}\) or stay in a closed orbit if \(\alpha = 0\text{.}\) The equilibrium points are spiral sinks and spiral sources, or centers, respectively.
If \(T^2 - 4D \lt 0\text{,}\) then we have a complex eigenvalues, and the type of equilibrium point depends on the real part of the eigenvalue. The sign of the real part is determined solely by \(T\text{.}\) If \(T \gt 0\) we have a source. If \(T \lt 0\text{,}\) we have a sink. If \(T = 0\text{,}\) we have a center. See Figure 3.7.5.
Since we are considering the case \(T \gt 0\text{,}\) we have
\begin{equation*}
\sqrt{T^2 - 4D} \lt T
\end{equation*}
and the value of the second eigenvalue \((T - \sqrt{T^2 - 4D}\,)/2\) is postive. Therefore, any point in the first quadrant below the parabola corresponds to a system with two positive eigenvalues and must correspond to a nodal source.
One the other hand, suppose that \(T \lt 0\text{.}\) Then the eigenvalue \((T - \sqrt{T^2 - 4D}\,)/2\) is always negative, and we need to determine if other eigenvalue is positive or negative. If \(D \lt 0\text{,}\) then \(T^2 - 4D \gt T^2\) and \(\sqrt{T^2 - 4D} \gt T\text{.}\) Therefore, the other eigenvalue \((T - \sqrt{T^2 - 4D}\,)/2\) is positive, telling us that any point in the fourth quadrant must correspond to a saddle. If \(D \gt 0\text{,}\) then \(\sqrt{T^2 - 4D} \lt T\) and the second eigenvalue is negative. In this case, we will have a nodal sink. We summarize our findings in Figure 3.7.6.
\begin{equation*}
A =
\begin{pmatrix} -r_A/V \amp + r_B/V \\
r_A / V \amp - r_A / V
\end{pmatrix}.
\end{equation*}
Computing the trace and determinant of the matrix yields \(T = - 2 r_A/V\) and \(D = (r_A^2 - r_A r_B)/V^2\text{,}\) where \(r_A\) and \(r_B\) are both positive. Certainly, \(T \lt 0\) and
Subsection3.7.2Parameterized Families of Linear Systems
The trace-determinant plane is an example of a parameter plane. We can adjust the entries of a matrix \(A\) and, thus, change the value of the trace and the determinant.
Recall that a harmonic oscillator can be modeled by the second-order equation
\begin{equation*}
m \frac{d^2 x}{dt^2} + b \frac{dx}{dt} + k x = 0,
\end{equation*}
where \(m > 0\) is the mass, \(b \geq 0\) is the damping coefficient, and \(k \gt 0\) is the spring constant. If we rewrite this equation as a first-order system, we have
Thus, for the harmonic oscillator \(T = -b/m\) and \(D= k/m\text{.}\) If we use the trace-determinant plane to analyze the harmonic oscillator, we need only concern ourselves with the second quadrant (Figure Figure 3.7.9).
If \((T, D) = (-b/m, k/m)\) lies above the parabola, we have an underdamped oscillator. If \((T, D) = (-b/m, k/m)\) lies below the parabola, we have an overdamped oscillator. If \((T, D) = (-b/m, k/m)\) lies on the parabola, we have a critically damped oscillator. If \(b = 0\text{,}\) we have an undamped oscillator.
Now let us see what happens to our harmonic oscillator when we fix \(m = 1\) and \(k = 3\) and let the damping \(b\) vary between zero and infinity. We can rewrite our system as
The line \(D = 3\) in the trace-determinant plane crosses the repeated eigenvalue parabola, \(D = T^2/4\) if \(b^2 = 12\) or when \(b = 2 \sqrt{3}\text{.}\) If \(b = 0\text{,}\) we have purely imaginary eigenvalues. This is the undamped harmonic oscillator. If \(0 \lt b \lt 2 \sqrt{3}\text{,}\) the eigenvalues are complex with a nonzero real part—the underdamped case. If \(b = 2 \sqrt{3}\text{,}\) the eigenvalues are negative and repeated—the critically damped case. Finally, if \(b \gt 2 \sqrt{3}\text{,}\) we have the overdamped case. In this case, the eigenvalues are real, distinct, and negative. A bifurcation occurs at \(b = 2 \sqrt{3}\text{.}\)
Thus, a bifurcation occurs at \(a = 1/2\text{.}\) If \(a \gt 1/2\text{,}\) we have a spiral sink. If \(a \lt 1/2\text{,}\) we have a sink with real eigenvalues. Further more, if \(a \lt 0\text{,}\) our sink becomes a saddle (Figure 3.7.14).
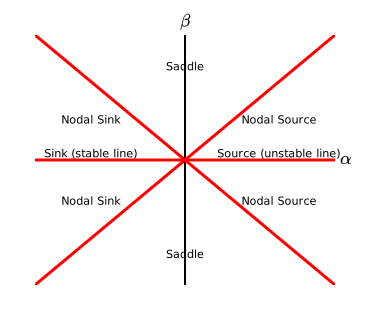
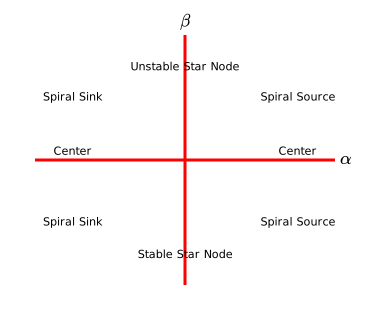
Identify all of the regions in the \(\alpha\beta\)-plane where the system \(d\mathbf x/dt = A \mathbf x\) possesses a saddle, a sink, a spiral sink, and so on. Plot your results on the \(\alpha\beta\)-plane.
Although the trace-determinant plane gives us a great deal of information about our system, we can not determine everything from this parameter plane. For example, the matrices
both have the same trace and determinant, but the solutions to \({\mathbf x}' = A {\mathbf x}\) wind around the origin in a clockwise direction while those of \({\mathbf x}' = B{\mathbf x}\) wind around in a counterclockwise direction.
If a \(2 \times 2\) matrix \(A\) has eigenvalues \(\lambda_1\) and \(\lambda_2\text{,}\) then \(\trace(A)\) is \(\lambda_1 + \lambda_2\) and \(\det(A) = \lambda_1 \lambda_2\text{.}\)
The trace-determinant plane is separated by the graph of the parabola \(D= T^2/4\) on the \(TD\)-plane. Points on the trace-determinant plane correspond to the trace and determinant of a linear system \({\mathbf x}' = A {\mathbf x}\text{.}\) Since the trace and the determinant of a matrix determine the eigenvalues of \(A\text{,}\) we can use the trace-determinant plane to parameterize the phase portraits of linear systems.
Classify the equilibrium points of the system \(\mathbf x' = A \mathbf x\) based on the position of \((T, D)\) in the trace-determinant plane in Exercise Group 3.7.5.1–8. Sketch the phase portrait by hand and then use Sage to verify your result.
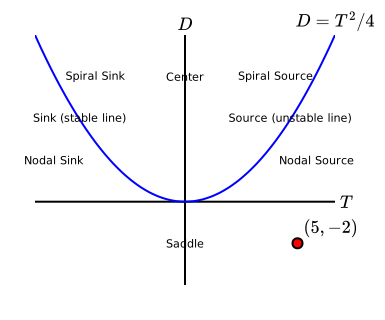
For \(A = \begin{pmatrix}1&2\\3&4\end{pmatrix}\text{,}\) the trace and determinant are
\begin{equation*}
T = \operatorname{tr}(A) = 5, \qquad
D = \det(A) = 4 - 6 = -2.
\end{equation*}
Since \(D \lt 0\text{,}\) the point \((T, D) = (5, -2)\) lies below the horizontal axis in the trace-determinant plane. This region corresponds to real eigenvalues of opposite sign, so the equilibrium at the origin is an unstable saddle.
Solutions on the stable manifold (along \(\mathbf{v}_2\)) decay to the origin; all other solutions diverge along directions asymptotically parallel to \(\mathbf{v}_1\text{.}\)
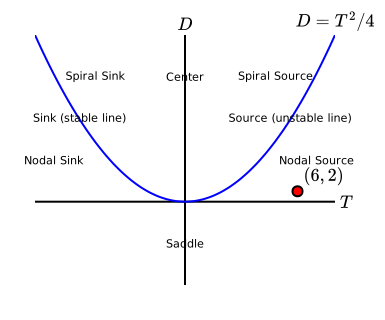
For \(A = \begin{pmatrix}4&2\\3&2\end{pmatrix}\text{,}\) the trace and determinant are
\begin{equation*}
T = \operatorname{tr}(A) = 6, \qquad
D = \det(A) = 8 - 6 = 2.
\end{equation*}
Since \(D \gt 0\text{,}\)\(T \gt 0\text{,}\) and the discriminant \(T^2 - 4D = 36 - 8 = 28 \gt 0\text{,}\) the point \((T, D) = (6, 2)\) lies above the \(T\)-axis and above the parabola \(D = T^2/4\) in the trace-determinant plane. This region corresponds to two distinct positive real eigenvalues, so the equilibrium at the origin is an unstable node.
All solutions diverge from the origin; trajectories leave tangent to \(\mathbf{v}_2\) (the slower direction) and become asymptotically parallel to \(\mathbf{v}_1\) as \(t \to \infty\text{.}\)
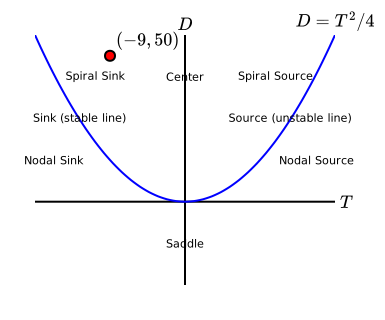
For \(A = \begin{pmatrix}-3&-8\\4&-6\end{pmatrix}\text{,}\) the trace and determinant are
\begin{gather*}
T = \operatorname{tr}(A) = -9,\\
D = \det(A) = (-3)(-6) - (-8)(4) = 50.
\end{gather*}
Since \(D \gt 0\text{,}\)\(T \lt 0\text{,}\) and the discriminant \(T^2 - 4D = 81 - 200 = -119 \lt 0\text{,}\) the point \((T, D) = (-9, 50)\) lies above the parabola \(D = T^2/4\) with \(T \lt 0\) in the trace-determinant plane. This region corresponds to complex eigenvalues with negative real part, so the equilibrium at the origin is a stable spiral.
with real part \(\alpha = -9/2 \lt 0\) and angular frequency \(\beta = \sqrt{119}/2 \approx 5.45\text{.}\) All solutions spiral toward the origin as \(t \to \infty\text{.}\)
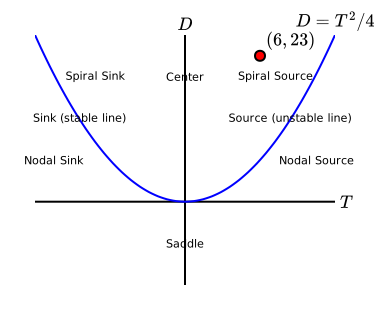
For \(A = \begin{pmatrix}4&-5\\3&2\end{pmatrix}\text{,}\) the trace and determinant are
\begin{gather*}
T = \operatorname{tr}(A) = 6,\\
D = \det(A) = (4)(2) - (-5)(3) = 23.
\end{gather*}
Since \(D \gt 0\text{,}\)\(T \gt 0\text{,}\) and the discriminant \(T^2 - 4D = 36 - 92 = -56 \lt 0\text{,}\) the point \((T, D) = (6, 23)\) lies above the parabola \(D = T^2/4\) with \(T \gt 0\) in the trace-determinant plane. This region corresponds to complex eigenvalues with positive real part, so the equilibrium at the origin is an unstable spiral.
with real part \(\alpha = 3 \gt 0\) and angular frequency \(\beta = \sqrt{14} \approx 3.74\text{.}\) All non-trivial solutions spiral away from the origin as \(t \to \infty\text{.}\)
For \(A = \begin{pmatrix}-11&10\\4&-5\end{pmatrix}\text{,}\) the trace and determinant are
\begin{gather*}
T = \operatorname{tr}(A) = -16,\\
D = \det(A) = (-11)(-5) - (10)(4) = 15.
\end{gather*}
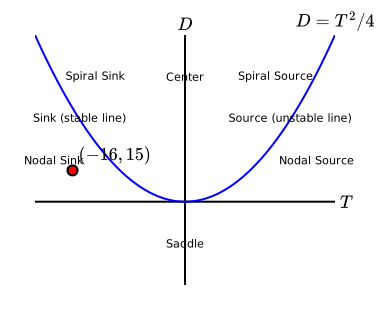
Since \(D \gt 0\text{,}\)\(T \lt 0\text{,}\) and the discriminant \(T^2 - 4D = 256 - 60 = 196 \gt 0\text{,}\) the point \((T, D) = (-16, 15)\) lies above the \(T\)-axis and below the parabola \(D = T^2/4\) with \(T \lt 0\) in the trace-determinant plane. This region corresponds to two distinct negative real eigenvalues, so the equilibrium at the origin is a stable node.
All solutions decay to the origin; since \(\lambda_2 = -15\) decays much faster, trajectories approach the origin tangent to the dominant eigenvector direction \(\mathbf{v}_1 = (1,1)^T\text{.}\)
For \(A = \begin{pmatrix}5&-3\\-8&-6\end{pmatrix}\text{,}\) the trace and determinant are
\begin{gather*}
T = \operatorname{tr}(A) = -1,\\
D = \det(A) = (5)(-6) - (-3)(-8) = -54.
\end{gather*}
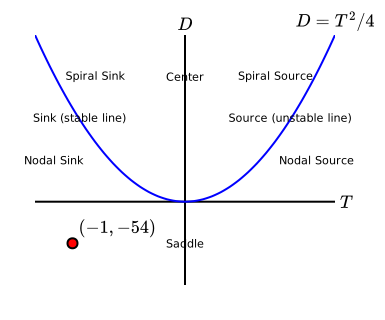
Since \(D \lt 0\text{,}\) the point \((T, D) = (-1, -54)\) lies below the horizontal axis in the trace-determinant plane. This region corresponds to real eigenvalues of opposite sign, so the equilibrium at the origin is an unstable saddle.
Solutions on the stable manifold (along \(\mathbf{v}_2\)) approach the origin; all other solutions are eventually repelled along directions parallel to \(\mathbf{v}_1\text{.}\)
For \(A = \begin{pmatrix}4&-15\\3&-8\end{pmatrix}\text{,}\) the trace and determinant are
\begin{gather*}
T = \operatorname{tr}(A) = -4,\\
D = \det(A) = (4)(-8) - (-15)(3) = 13.
\end{gather*}
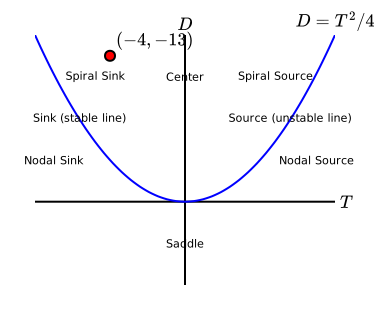
Since \(D \gt 0\text{,}\)\(T \lt 0\text{,}\) and the discriminant \(T^2 - 4D = 16 - 52 = -36 \lt 0\text{,}\) the point \((T, D) = (-4, 13)\) lies above the parabola \(D = T^2/4\) with \(T \lt 0\) in the trace-determinant plane. This region corresponds to complex eigenvalues with negative real part, so the equilibrium at the origin is a stable spiral.
For \(A = \begin{pmatrix}4&11\\-8&-3\end{pmatrix}\text{,}\) the trace and determinant are
\begin{gather*}
T = \operatorname{tr}(A) = 1,\\
D = \det(A) = (4)(-3) - (11)(-8) = 76.
\end{gather*}
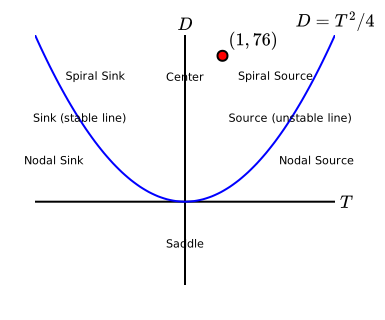
Since \(D \gt 0\text{,}\)\(T \gt 0\text{,}\) and the discriminant \(T^2 - 4D = 1 - 304 = -303 \lt 0\text{,}\) the point \((T, D) = (1, 76)\) lies above the parabola \(D = T^2/4\) with \(T \gt 0\) in the trace-determinant plane. This region corresponds to complex eigenvalues with positive real part, so the equilibrium at the origin is an unstable spiral.
with real part \(\alpha = \tfrac{1}{2} \gt 0\) and angular frequency \(\beta = \tfrac{\sqrt{303}}{2} \approx 8.72\text{.}\) All non-trivial solutions spiral away from the origin as \(t \to \infty\text{.}\)
Each of the following matrices in Exercise Group 3.7.5.9–14 describes a family of differential equations \(\mathbf x' = A \mathbf x\) that depends on the parameter \(\alpha\text{.}\) For each one-parameter family sketch the curve in the trace-determinant plane determined by \(\alpha\text{.}\) Identify any values of \(\alpha\) where the type of system changes. These values are bifurcation values of \(\alpha\text{.}\)
For \(A = \begin{pmatrix}\alpha&3\\-1&0\end{pmatrix}\text{,}\) the trace and determinant are
\begin{equation*}
T = \alpha, \qquad D = 3.
\end{equation*}
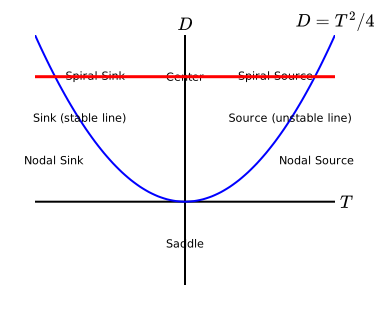
As \(\alpha\) varies, the point \((T,D) = (\alpha, 3)\) traces the horizontal line \(D = 3\) in the trace-determinant plane. The discriminant is \(T^2 - 4D = \alpha^2 - 12\text{.}\)
\(\alpha = 0\text{:}\)\(T = 0\) with \(D \gt 0\text{;}\) the equilibrium is a center (purely imaginary eigenvalues). This is a bifurcation: the stability changes from stable to unstable.
For \(A = \begin{pmatrix}\alpha&3\\\alpha&0\end{pmatrix}\text{,}\) the trace and determinant are
\begin{equation*}
T = \alpha, \qquad D = (α)(0) - (3)(\alpha) = -3\alpha.
\end{equation*}
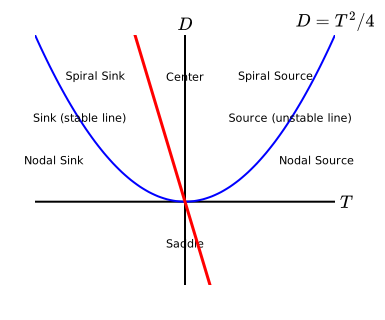
As \(\alpha\) varies, the point \((T, D) = (\alpha, -3\alpha)\) traces the line \(D = -3T\) in the trace-determinant plane, passing through the origin with slope \(-3\text{.}\) The discriminant is
The type of equilibrium changes at the following values of \(\alpha\text{:}\)
\(\alpha = 0\text{:}\)\(D = 0\text{,}\) so the origin is not an isolated equilibrium. This is a bifurcation point where the nature of the system changes fundamentally.
\(\alpha = 0\) (\(T=0\text{,}\)\(D=0\)): the origin of the trace-determinant plane. The determinant is zero, so the equilibrium is not isolated — a bifurcation.
For \(A = \begin{pmatrix}1&2\\\alpha&0\end{pmatrix}\text{,}\) the trace and determinant are
\begin{equation*}
T = 1, \qquad D = -2\alpha.
\end{equation*}
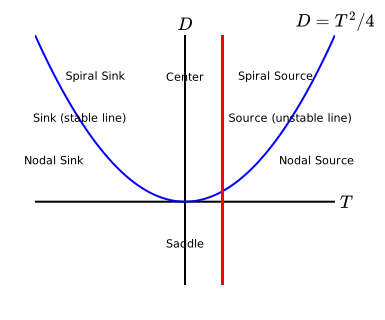
As \(\alpha\) varies, the point \((T, D) = (1, -2\alpha)\) traces the vertical line \(T = 1\) in the trace-determinant plane, traversed downward as \(\alpha\) increases. The discriminant along the line is
The type of equilibrium changes at the following values of \(\alpha\text{:}\)
\(\alpha = -\tfrac{1}{8}\) (\(D = \tfrac{1}{4} = T^2/4\)): the line meets the parabola \(D = T^2/4\text{;}\) transition from unstable spiral to unstable node.
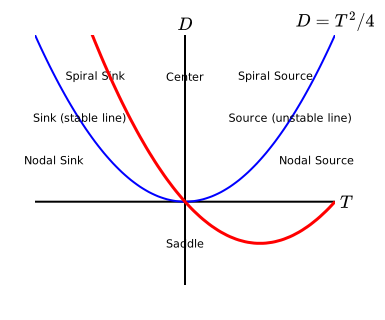
so the curve is a downward-shifted parabola\(D = T^2/4 - 5/4\text{,}\) lying entirely below the standard parabola \(D = T^2/4\) by \(5/4\text{.}\) The discriminant along the curve is
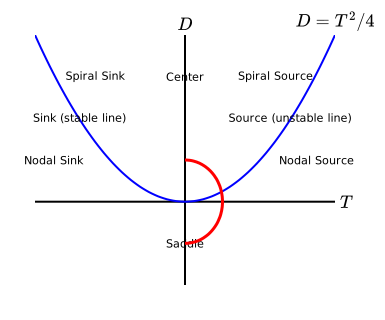
so the curve is the right semicircle\(T^2 + D^2 = 1\) with \(T \geq 0\text{,}\) traversed from \((T,D)=(0,1)\) at \(\alpha=-1\) clockwise to \((T,D)=(0,-1)\) at \(\alpha=1\text{.}\) The discriminant along the curve is
For the matrix \(A = \begin{pmatrix}\alpha&\beta\\1&0\end{pmatrix}\text{,}\) the trace and determinant are
\begin{equation*}
T = \alpha, \qquad D = -\beta,
\end{equation*}
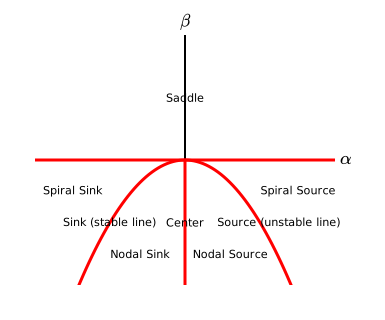
and the discriminant is \(\Delta = T^2 - 4D = \alpha^2 + 4\beta\text{.}\) The type of equilibrium at the origin is therefore determined entirely by the position of \((\alpha, \beta)\) in the \(\alpha\beta\)-plane as follows.
The boundary curves dividing the parameter plane into regions are:
\(\beta = 0\) (the \(\alpha\)-axis): \(D = 0\text{,}\) so the equilibrium is non-isolated (degenerate). For \(\beta \gt 0\) we have \(D \lt 0\) giving a saddle; for \(\beta \lt 0\) we have \(D \gt 0\) giving a node, spiral, or center.
\(\beta = -\alpha^2/4\) (downward-opening parabola): \(\Delta = 0\text{,}\) giving an improper node. Above this parabola (\(\beta \gt -\alpha^2/4\)) the eigenvalues are complex; below (\(\beta \lt -\alpha^2/4\)) they are real and distinct.
These two lines divide the \(\alpha\beta\)-plane into four regions. Additionally, the line \(\beta = 0\) (with \(\alpha \neq 0\)) gives a repeated eigenvalue \(\lambda = \alpha\) (improper node). The complete classification is:
which are complex whenever \(\beta \neq 0\) and real (repeated) when \(\beta = 0\text{.}\) Since \(D = \alpha^2 + \beta^2 \geq 0\) everywhere, saddles never occur. The behavior is determined entirely by the sign of \(\alpha\) (the real part of the eigenvalue) and whether \(\beta = 0\text{.}\)
Note that the classification depends only on \(\alpha\) (not on \(|\beta|\) for \(\beta \neq 0\)), so the entire left half-plane is a stable spiral, the right half-plane is an unstable spiral, and the \(\beta\)-axis is a center (for \(\beta \neq 0\)).